- ISSN 0258-2724
- CN 51-1277/U
- EI Compendex
- Scopus
- Indexed by Core Journals of China, Chinese S&T Journal Citation Reports
- Chinese S&T Journal Citation Reports
- Chinese Science Citation Database
| Citation: | GAO Tao, WANG Long, YANG Jie, ZHOU Fazhu. Nonsingular Terminal Sliding Mode Control Strategy For Maglev Systems Based On Improved LESO[J]. Journal of Southwest Jiaotong University. doi: 10.3969/j.issn.0258-2724.20260179

|
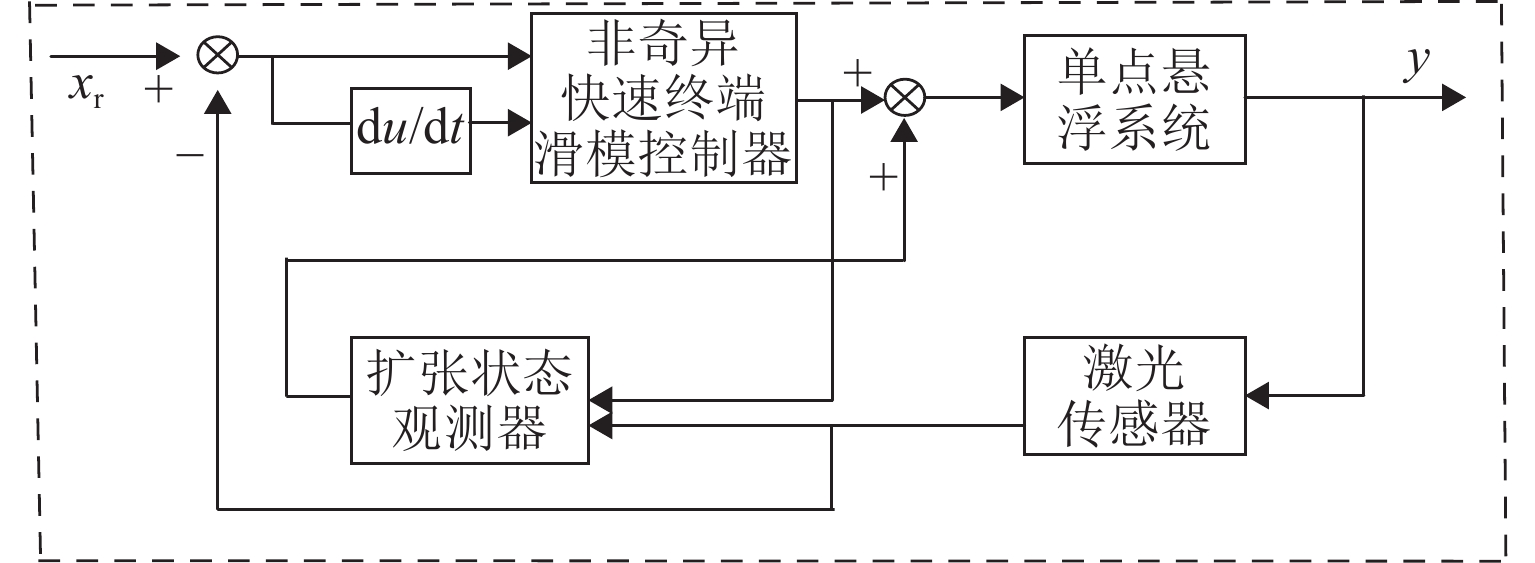
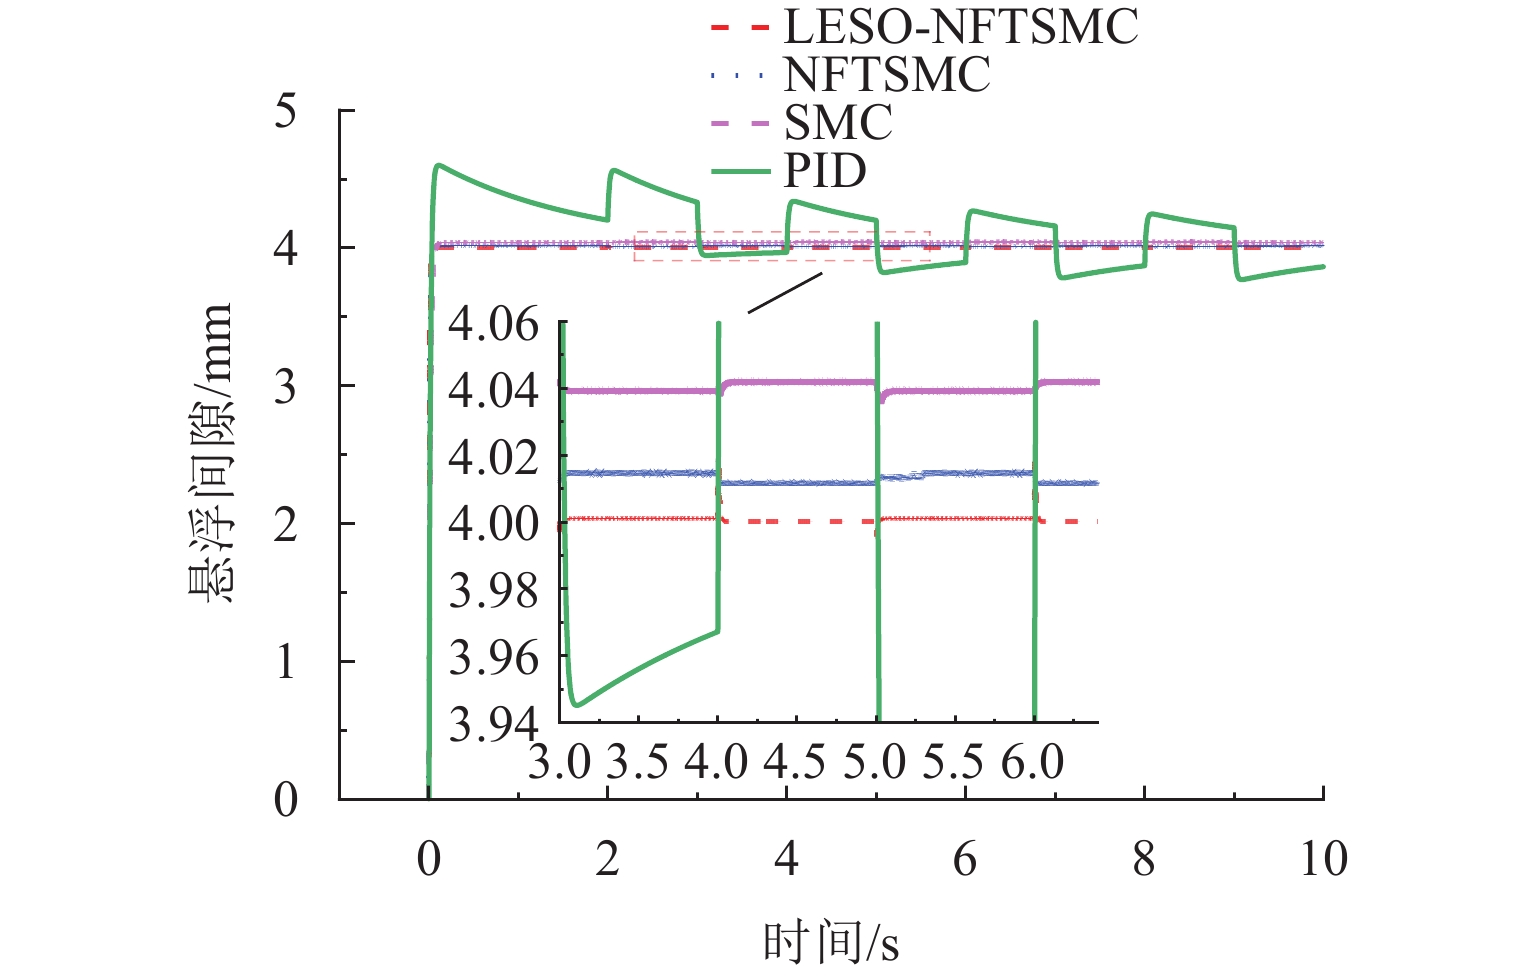
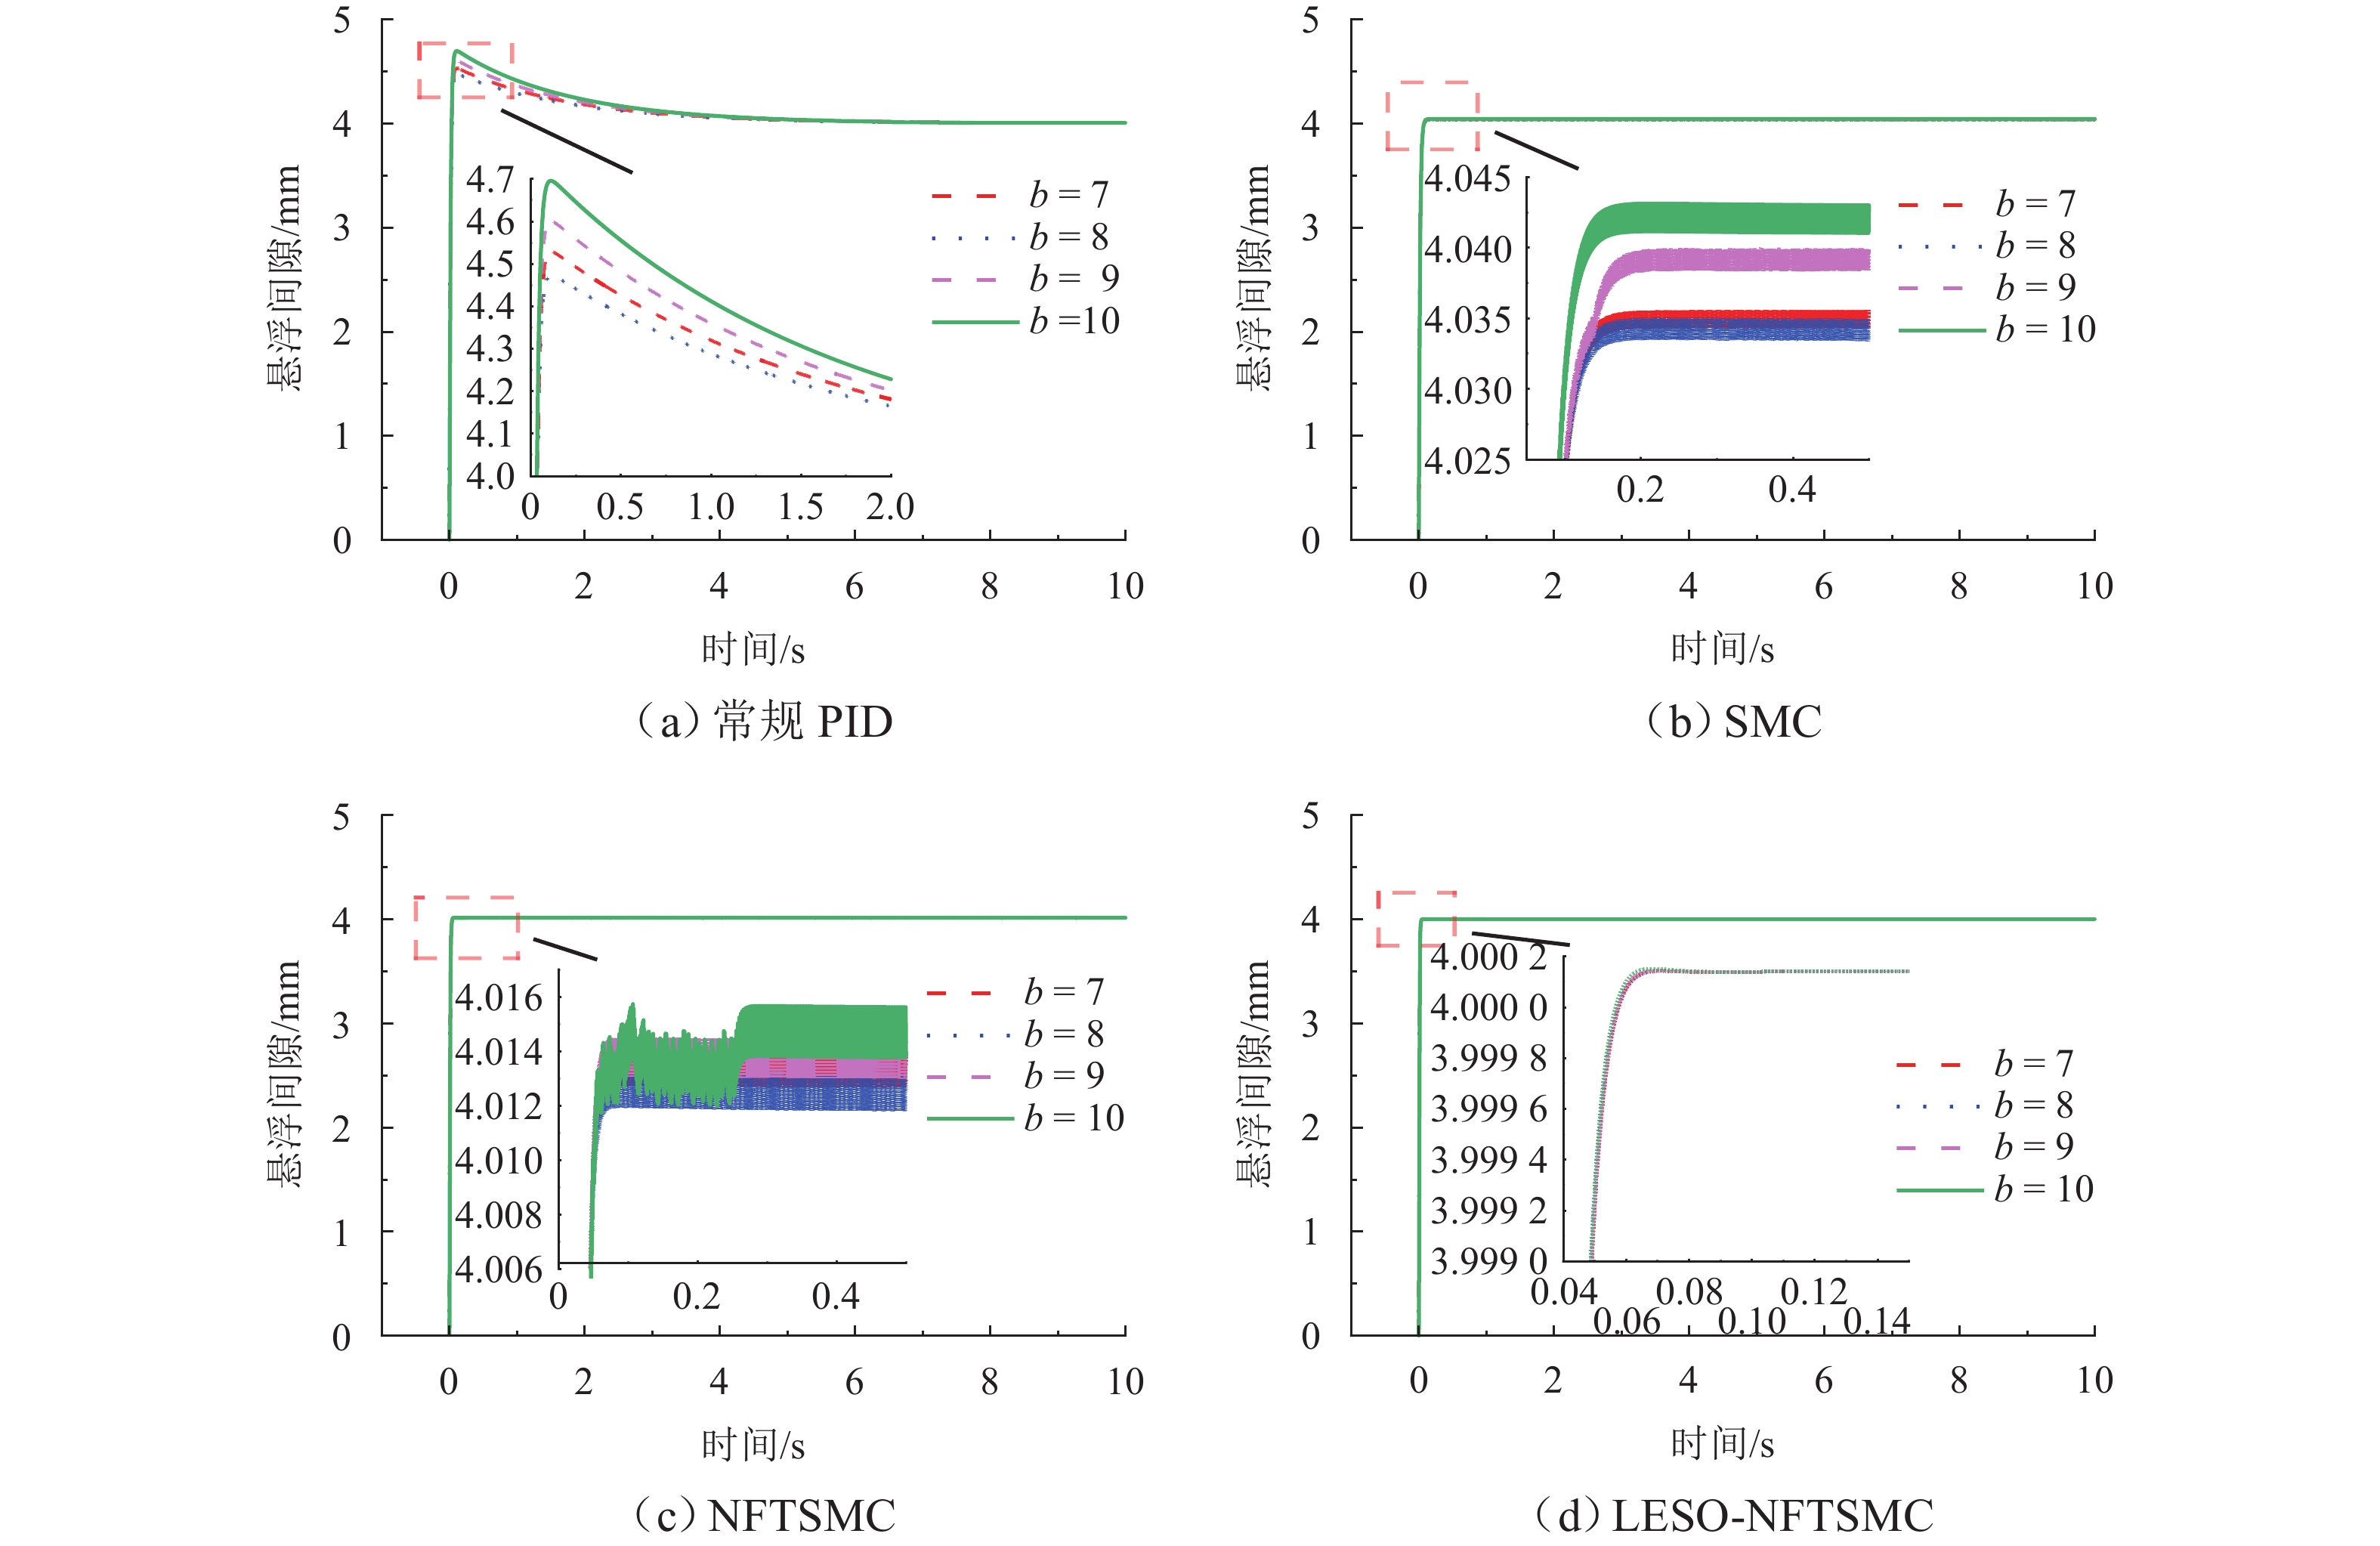
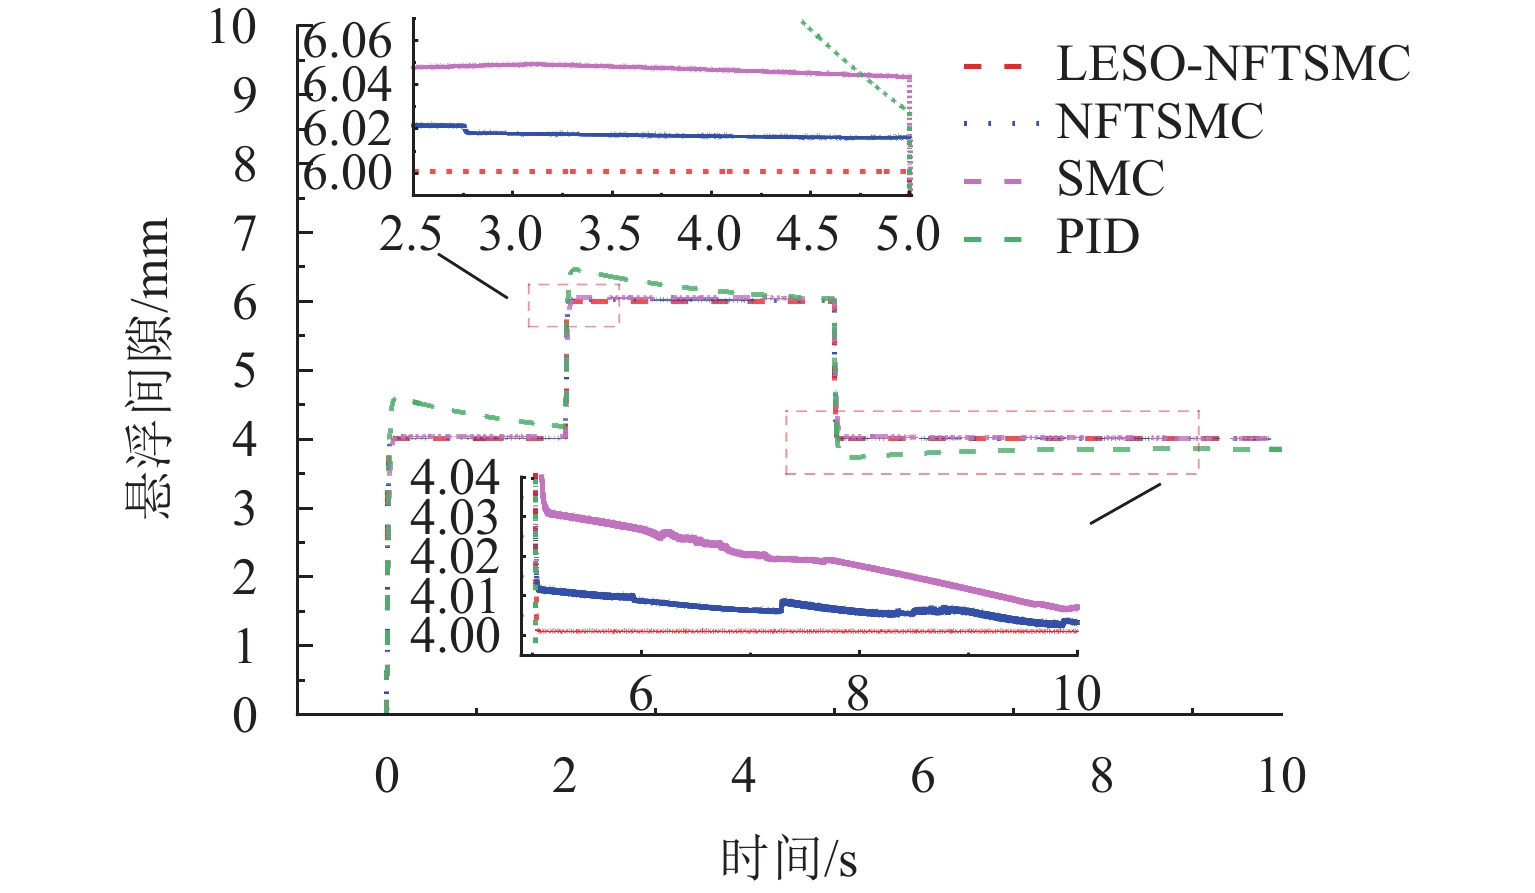
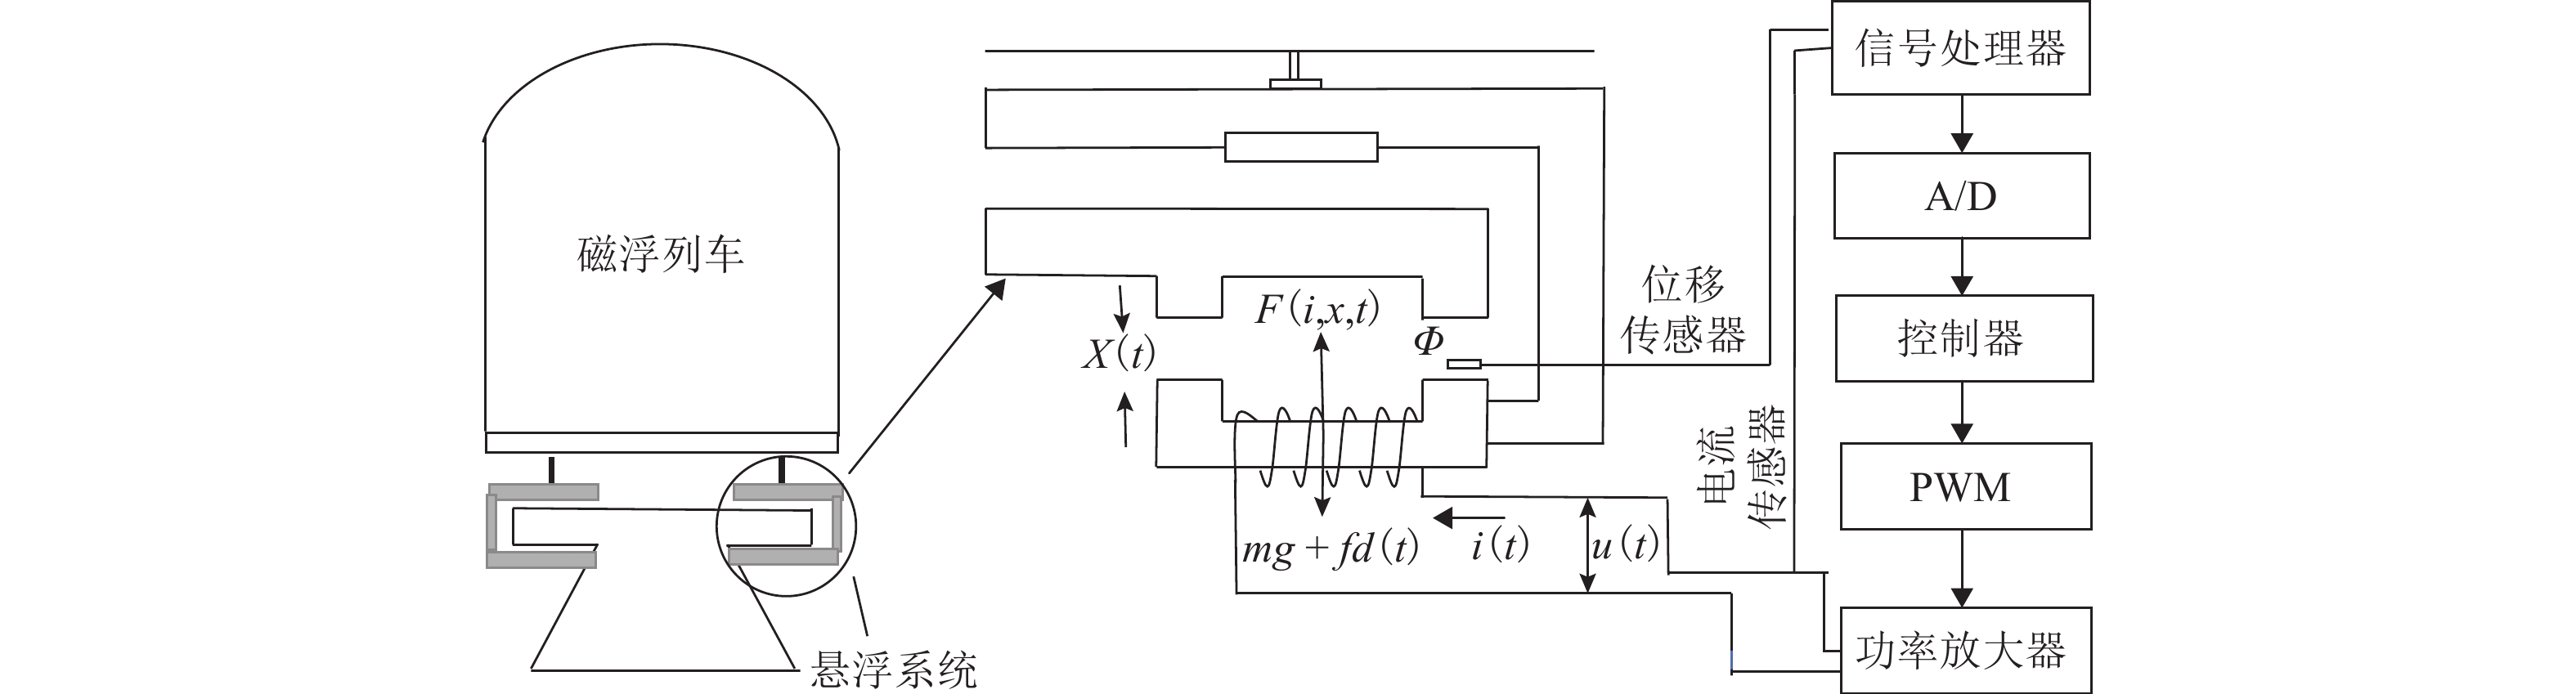
To address the degradation in dynamic levitation control performance caused by the strong mechanical nonlinearities inherent in single-point electromagnetic suspension (EMS) systems, along with external disturbances and internal parameter uncertainties, a nonsingular fast terminal sliding mode control (NFTSMC) strategy based on an improved linear extended state observer (LESO) is proposed. First, a nonlinear model of the single-electromagnet suspension system was established. Second, to tackle the issues of a slow convergence rate and chattering in conventional sliding mode control (SMC) when the system state is far from the sliding surface, a controller was designed based on a nonsingular fast terminal sliding mode surface, and a novel power reaching law was proposed by introducing an improved function. Third, system uncertainties, external disturbances, and modeling errors were collectively treated as a total disturbance, and an improved LESO was developed to estimate this disturbance in real time and provide dynamic compensation, effectively suppressing chattering and improving robustness against disturbances under complex operating conditions. Meanwhile, the finite-time convergence property of the tracking error was rigorously proved based on Lyapunov stability theory. Finally, comparative simulations and experiments with a PID controller, conventional SMC, and NFTSMC were conducted to verify the superiority of the proposed control algorithm in terms of system stability, dynamic response, and anti-disturbance capability. Experimental results demonstrate that the proposed LESO-NFTSMC controller exhibits favorable dynamic performance under external impact loading. Compared with SMC, the proposed controller reduces the settling time, chattering amplitude, and overshoot under external impact loading by 52.2%, 85.3%, and 63.6%, respectively, demonstrating its significant advantages in dynamic response, vibration suppression, and impact resistance.

| [1] |
丁叁叁. 时速600公里高速磁浮交通系统[M]. 上海: 上海科学技术出版社, 2022.
|
| [2] |
龙志强, 翟明达, 王志强, 等. 磁浮列车状态监测、故障诊断与容错控制[M]. 上海: 上海科学技术出版社, 2023.
|
| [3] |
Li F X, Sun Y G, Xu J Q, et al. Control methods for levitation system of EMS-type maglev vehicles: an overview[J]. Energies, 2023, 16(7): 2995. doi: 10.3390/en16072995
|
| [4] |
邓自刚, 刘宗鑫, 李海涛, 等. 磁悬浮列车发展现状与展望[J]. 西南交通大学学报, 2022, 57(3): 455-474, 530. doi: 10.3969/j.issn.0258-2724.20220001
Deng Zigang, Liu Zongxin, Li Haitao, et al. Development status and prospect of maglev train[J]. Journal of Southwest Jiaotong University, 2022, 57(3): 455-474,530. doi: 10.3969/j.issn.0258-2724.20220001
|
| [5] |
Gou J S. Development status and global competition trends analysis of maglev transportation technology based on patent data[J]. Urban Rail Transit, 2018, 4(3): 117-129. doi: 10.1007/s40864-018-0087-3
|
| [6] |
苏芷玄, 杨杰, 彭月, 等. 单点混合磁悬浮系统的自抗扰控制仿真研究[J]. 铁道科学与工程学报, 2022, 19(4): 864-873. doi: 10.19713/j.cnki.43-1423/u.T20210472
Su Zhixuan, Yang Jie, Peng Yue, et al. Simulating active disturbance-resistantcontrol of single-point hybrid magnetic suspension system[J]. Journal of Railway Science and Engineering, 2022, 19(4): 864-873. doi: 10.19713/j.cnki.43-1423/u.T20210472
|
| [7] |
Zhang Z Z, Pan Y L, Zi Z, et al. Stability and Hopf bifurcation analysis for a vertical active magnetic bearing system with dual feedback delays[J]. Mechanical Systems and Signal Processing, 2026, 250: 114158. doi: 10.1016/j.ymssp.2026.114158
|
| [8] |
Zhang L L, Huang L H. Hopf bifurcation analysis for a maglev system with two time delays[J]. Mechanical Systems and Signal Processing, 2025, 224: 112006. doi: 10.1016/j.ymssp.2024.112006
|
| [9] |
Zhang Z Z, Pan Y L, Zi Z, et al. Current differential signal extraction algorithm via fast-TD and its application in open-circuit fault diagnosis of magnetic bearings[J]. IEEE Transactions on Instrumentation and Measurement, 2025, 74: 3520811. doi: 10.1109/tim.2025.3551457
|
| [10] |
孙友刚, 张丹丹, 吉文, 等. 基于模糊补偿的磁浮列车悬浮系统非奇异终端滑模控制[J]. 西南交通大学学报, 2025, 60(4): 803-811. doi: 10.3969/j.issn.0258-2724.20240499
Sun Yougang, Zhang Dandan, Ji Wen, et al. Fuzzy compensation-based non-singular terminal sliding mode control of maglev vehicle levitation system[J]. Journal of Southwest Jiaotong University, 2025, 60(4): 803-811. doi: 10.3969/j.issn.0258-2724.20240499
|
| [11] |
Hu S, Qin Y, Yang J. Global fast terminal sliding mode control of magnetic levitation system based on improved extended state observer[J]. International Journal of Control, Automation and Systems, 2025, 23(5): 1469-1483. doi: 10.1007/s12555-024-1010-1
|
| [12] |
Abdollahzadeh M, Pourgholi M. Adaptive fuzzy sliding mode control of magnetic levitation system based on Interval Type-2 Fuzzy Neural Network Identification with an Extended Kalman–Bucy filter[J]. Engineering Applications of Artificial Intelligence, 2024, 130: 107645. doi: 10.1016/j.engappai.2023.107645
|
| [13] |
Lei C, Lan Y P, Xu Z L. Fractional order sliding mode control for linear maglev synchronous motor based on an adaptive fixed-time extended state observer[J]. Journal of Vibration and Control, 2024, 30(21/22): 4681-4694. doi: 10.1177/10775463231216133
|
| [14] |
Qiang H Y, Li W L, Sun Y G, et al. Levitation chassis dynamic analysis and robust position control for maglev vehicles under nonlinear periodic disturbance[J]. Journal of Vibroengineering, 2017, 19(2): 1273-1286. doi: 10.21595/jve.2016.17541
|
| [15] |
张露洁, 秦耀, 杨杰. 基于自适应反步滑模的磁悬浮系统非线性控制方法研究[J]. 铁道科学与工程学报, 2025(7): 2910-2920. doi: 10.19713/j.cnki.43-1423/u.T20241466
Zhang Lujie, Qin Yao, Yang Jie. Nonlinear control method of magnetic levitation system based on adaptive backstepping sliding mode[J]. Journal of Railway Science and Engineering, 2025(7): 2910-2920. doi: 10.19713/j.cnki.43-1423/u.T20241466
|
| [16] |
李至勇, 杨杰, 周发助, 等. 电磁悬浮系统的改进滑模控制方法[J]. 电子测量技术, 2024, 47(4): 87-94. doi: 10.19651/j.cnki.emt.2315007
Li Zhiyong, Yang Jie, Zhou Fazhu, et al. Improved sliding mode control method for electromagnetic levitation system[J]. Electronic Measurement Technology, 2024, 47(4): 87-94. doi: 10.19651/j.cnki.emt.2315007
|
| [17] |
Boukattaya M, Mezghani N, Damak T. Adaptive nonsingular fast terminal sliding-mode control for the tracking problem of uncertain dynamical systems[J]. ISA Transactions, 2018, 77: 1-19. doi: 10.1016/j.isatra.2018.04.007
|
| [18] |
Liu Z T, Wang X, Zhou P, et al. Non-singular fast terminal composite sliding mode control of marine permanent magnet synchronous propulsion motors[J]. Machines, 2025, 13(6): 470. doi: 10.3390/machines13060470
|
| [19] |
张合新, 范金锁, 孟飞, 等. 一种新型滑模控制双幂次趋近律[J]. 控制与决策, 2013, 28(2): 289-293. doi: 10.13195/j.cd.2013.02.132.zhanggx.028
Zhang Hexin, Fan Jinsuo, Meng Fei, et al. A new type of sliding mode control double power convergence law[J]. Control and Decision, 2013, 28(2): 289-293. doi: 10.13195/j.cd.2013.02.132.zhanggx.028
|
| [20] |
孙佃升, 章跃进. 线性扩张状态观测器的改进及观测精度分析[J]. 国防科技大学学报, 2017, 39(6): 111-117. doi: 10.11887/j.cn.201706017
Sun Diansheng, Zhang Yuejin. Improvement and observation accuracy analysis of linear extended state observer[J]. Journal of National University of Defense Technology, 2017, 39(6): 111-117. doi: 10.11887/j.cn.201706017
|
| [21] |
高志强, 刘佳风, 周雪松, 等. 固态变压器整流级的滑模自抗扰设计与仿真[J]. 计算机应用与软件, 2024, 41(11): 93-100. doi: 10.3969/j.issn.1000-386x.2024.11.013
Gao Zhiqiang, Liu Jiafeng, Zhou Xuesong, et al. Sliding mode active disturbance rejection design and simulation for rectifier stage of solid state transformer[J]. Computer Applications and Software, 2024, 41(11): 93-100. doi: 10.3969/j.issn.1000-386x.2024.11.013
|
| [22] |
杨杰, 秦耀, 汪永壮, 等. 永磁电磁混合型磁浮球的改进滑模控制方法[J]. 湖南大学学报(自然科学版), 2023, 50(4): 200-209. doi: 10.16339/j.cnki.hdxbzkb.2023230
Yang Jie, Qin Yao, Wang Yongzhuang, et al. Improved sliding mode control method for permanent magnet electromagnetic hybrid magnetic levitation ball[J]. Journal of Hunan University (Natural Sciences), 2023, 50(4): 200-209. doi: 10.16339/j.cnki.hdxbzkb.2023230
|
| [23] |
马广富, 朱庆华, 王鹏宇, 等. 基于终端滑模的航天器自适应预设性能姿态跟踪控制[J]. 航空学报, 2018, 39(6): 136-146. doi: 10.7527/S1000-6893.2018.21763
Ma Guangfu, Zhu Qinghua, Wang Pengyu, et al. Adaptive prescribed performance attitude tracking control for spacecraft via terminal sliding-mode technique[J]. Acta Aeronautica et Astronautica Sinica, 2018, 39(6): 136-146. doi: 10.7527/S1000-6893.2018.21763
|
| [24] |
罗成, 唐浩, 万郭豪, 等. 双边永磁电磁混合型电动悬浮加速度反馈控制[J]. 西南交通大学学报, 2025, 60(4): 1024-1031. doi: 10.3969/j.issn.0258-2724.20240551
Luo Cheng, Tang Hao, Wan Guohao, et al. Acceleration feedback control of bilateral permanent magnet and electromagnetic hybrid electrodynamic suspension[J]. Journal of Southwest Jiaotong University, 2025, 60(4): 1024-1031. doi: 10.3969/j.issn.0258-2724.20240551
|
| [25] |
卢静, 马卫华, 李苗, 等. 永磁磁浮转向架的运动解耦与动力学响应[J]. 西南交通大学学报, 2025, 60(4): 930-943. doi: 10.3969/j.issn.0258-2724.20250162
Lu Jing, Ma Weihua, Li Miao, et al. Motion decoupling and dynamic response of permanent magnet maglev bogie[J]. Journal of Southwest Jiaotong University, 2025, 60(4): 930-943. doi: 10.3969/j.issn.0258-2724.20250162
|
Figures(9) / Tables(2)

 DownLoad: