- ISSN 0258-2724
- CN 51-1277/U
- EI Compendex
- Scopus
- Indexed by Core Journals of China, Chinese S&T Journal Citation Reports
- Chinese S&T Journal Citation Reports
- Chinese Science Citation Database
| Citation: | DU Chaofan, MING Zhengfeng, LIU Ding, CAI Luyang. I&I-Based Global Fast Terminal Sliding Mode Control with Disturbance Observer for Maglev Platform[J]. Journal of Southwest Jiaotong University. doi: 10.3969/j.issn.0258-2724.20250590

|
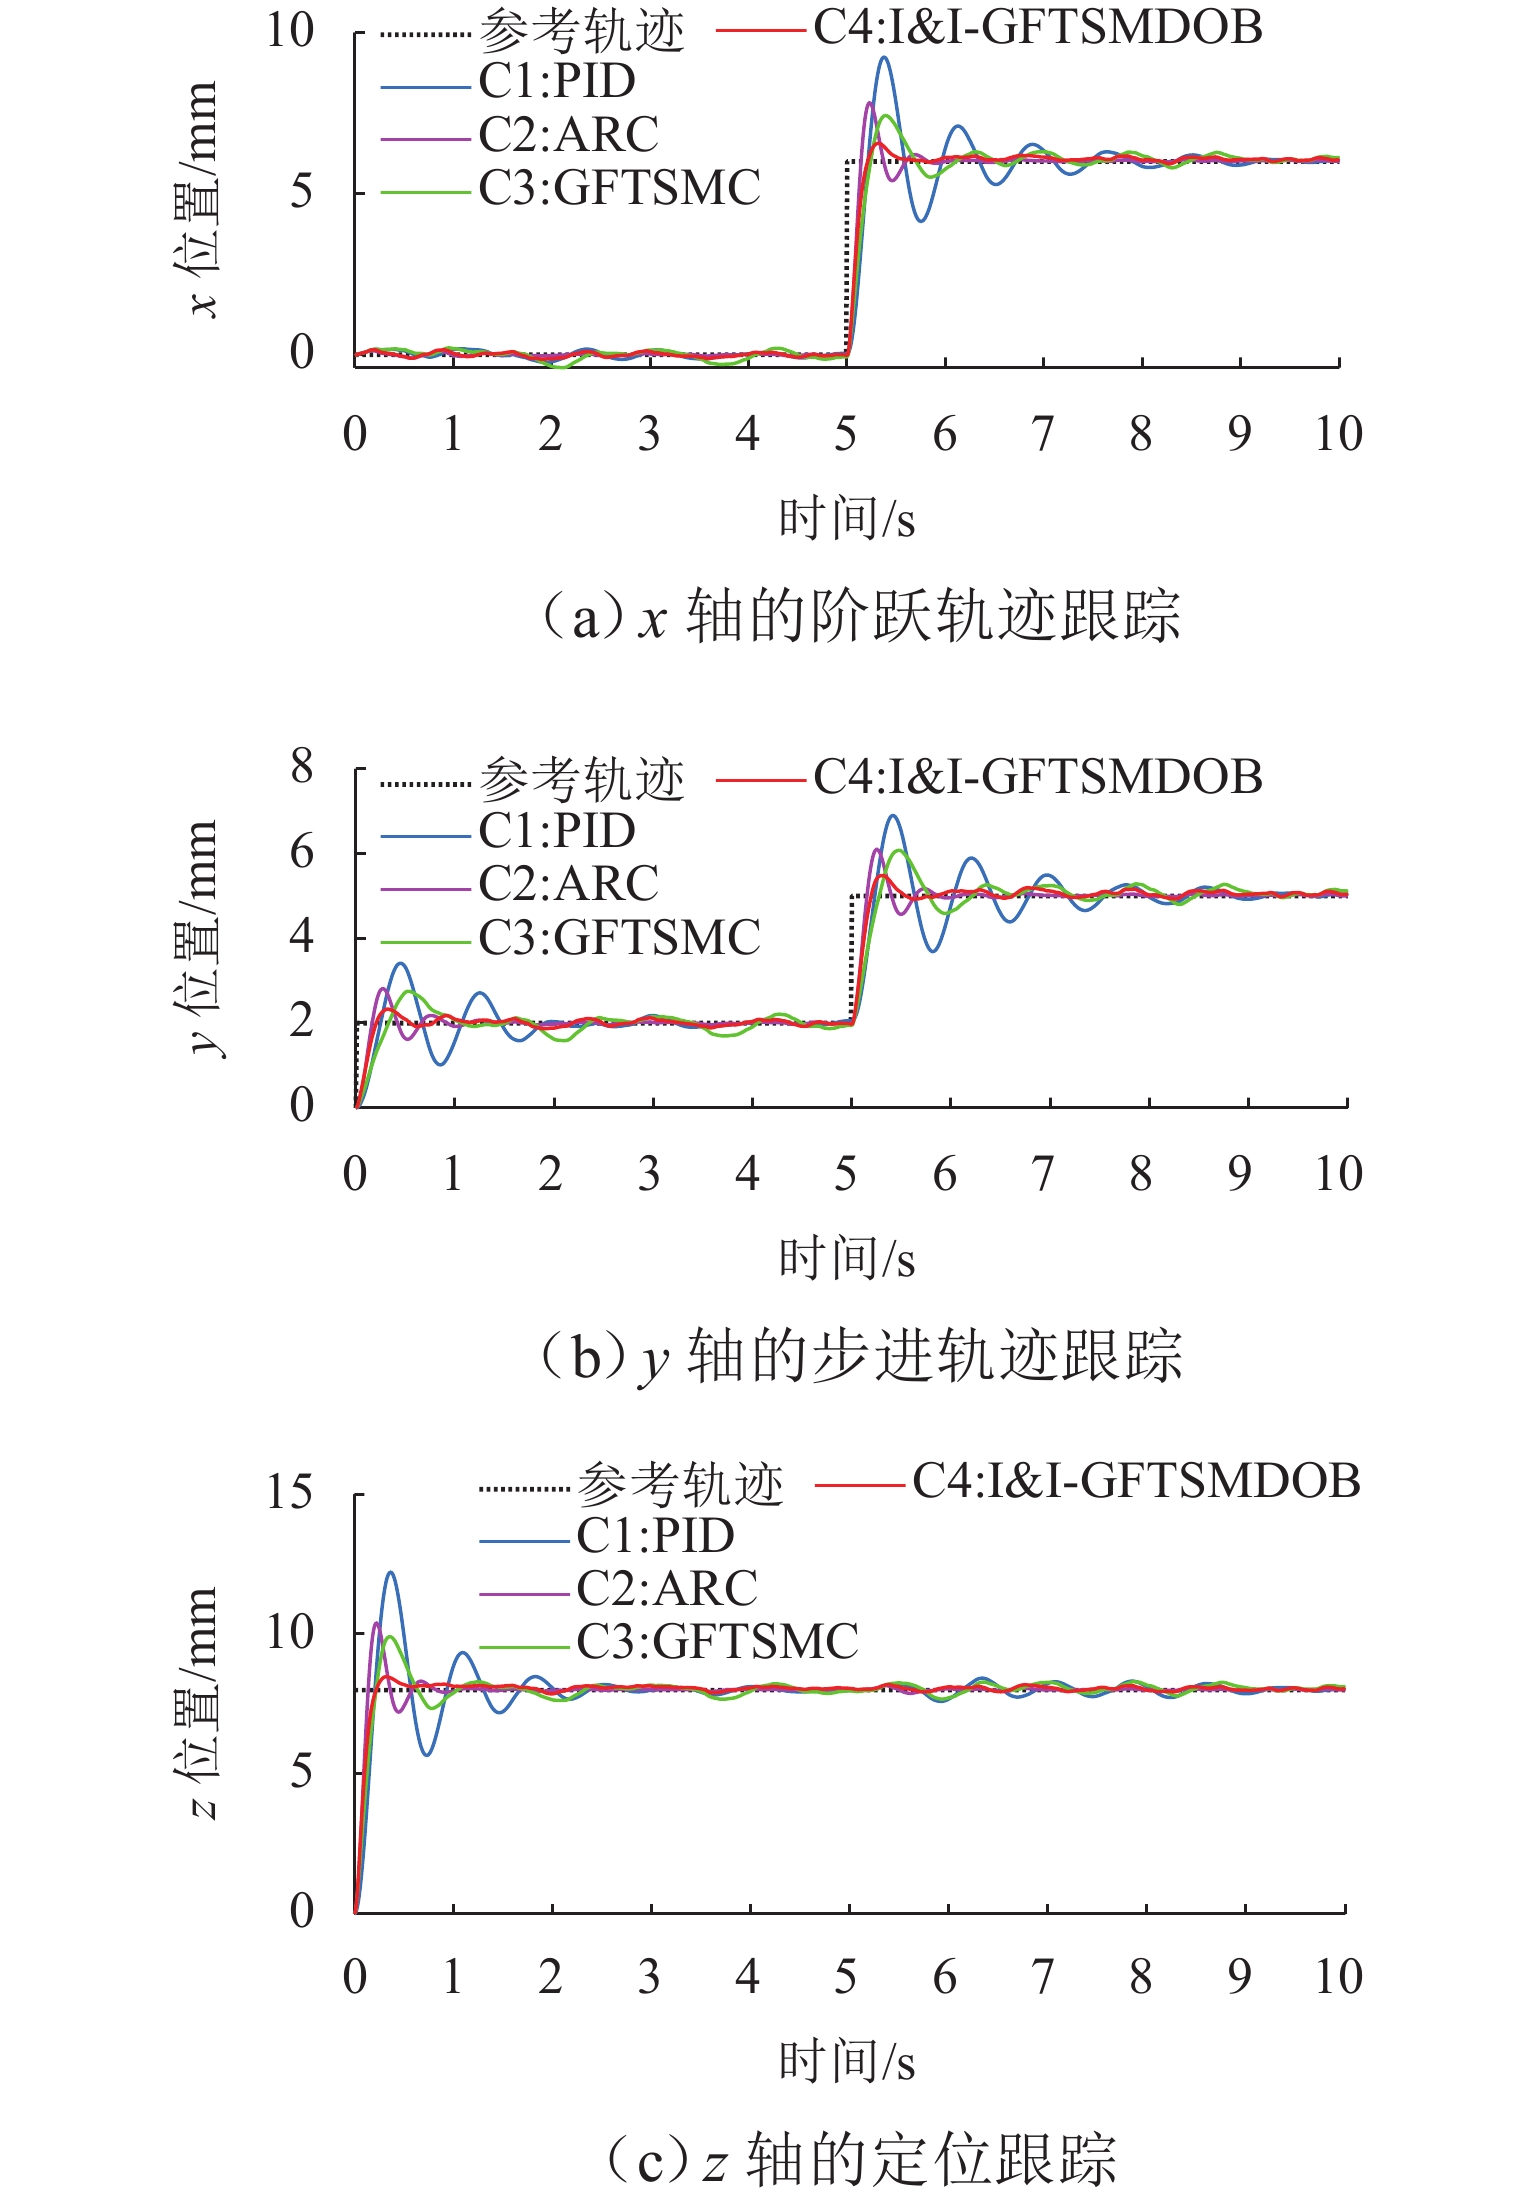
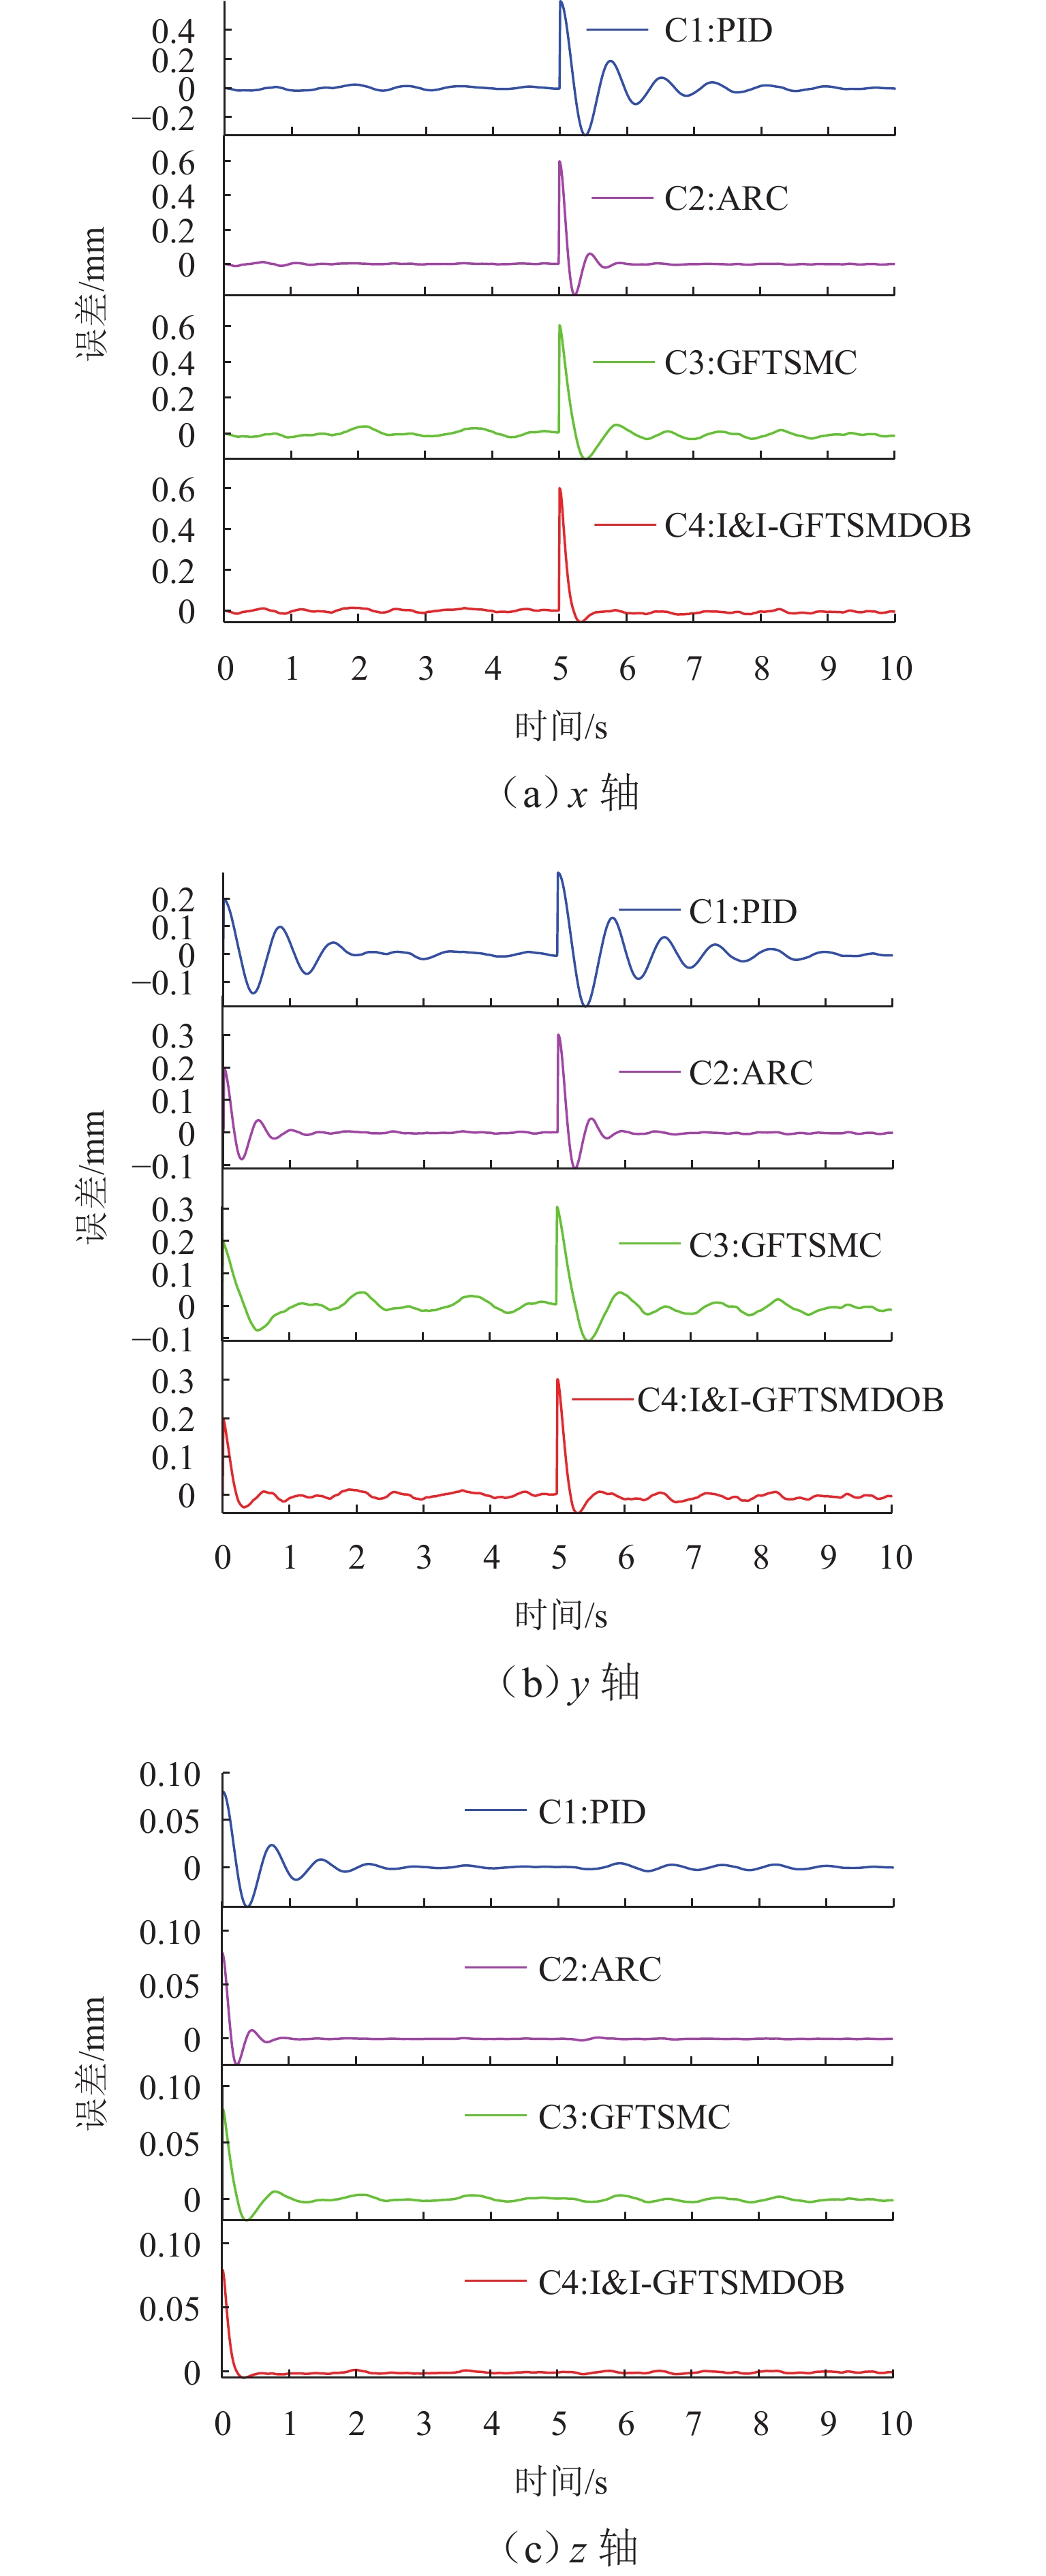
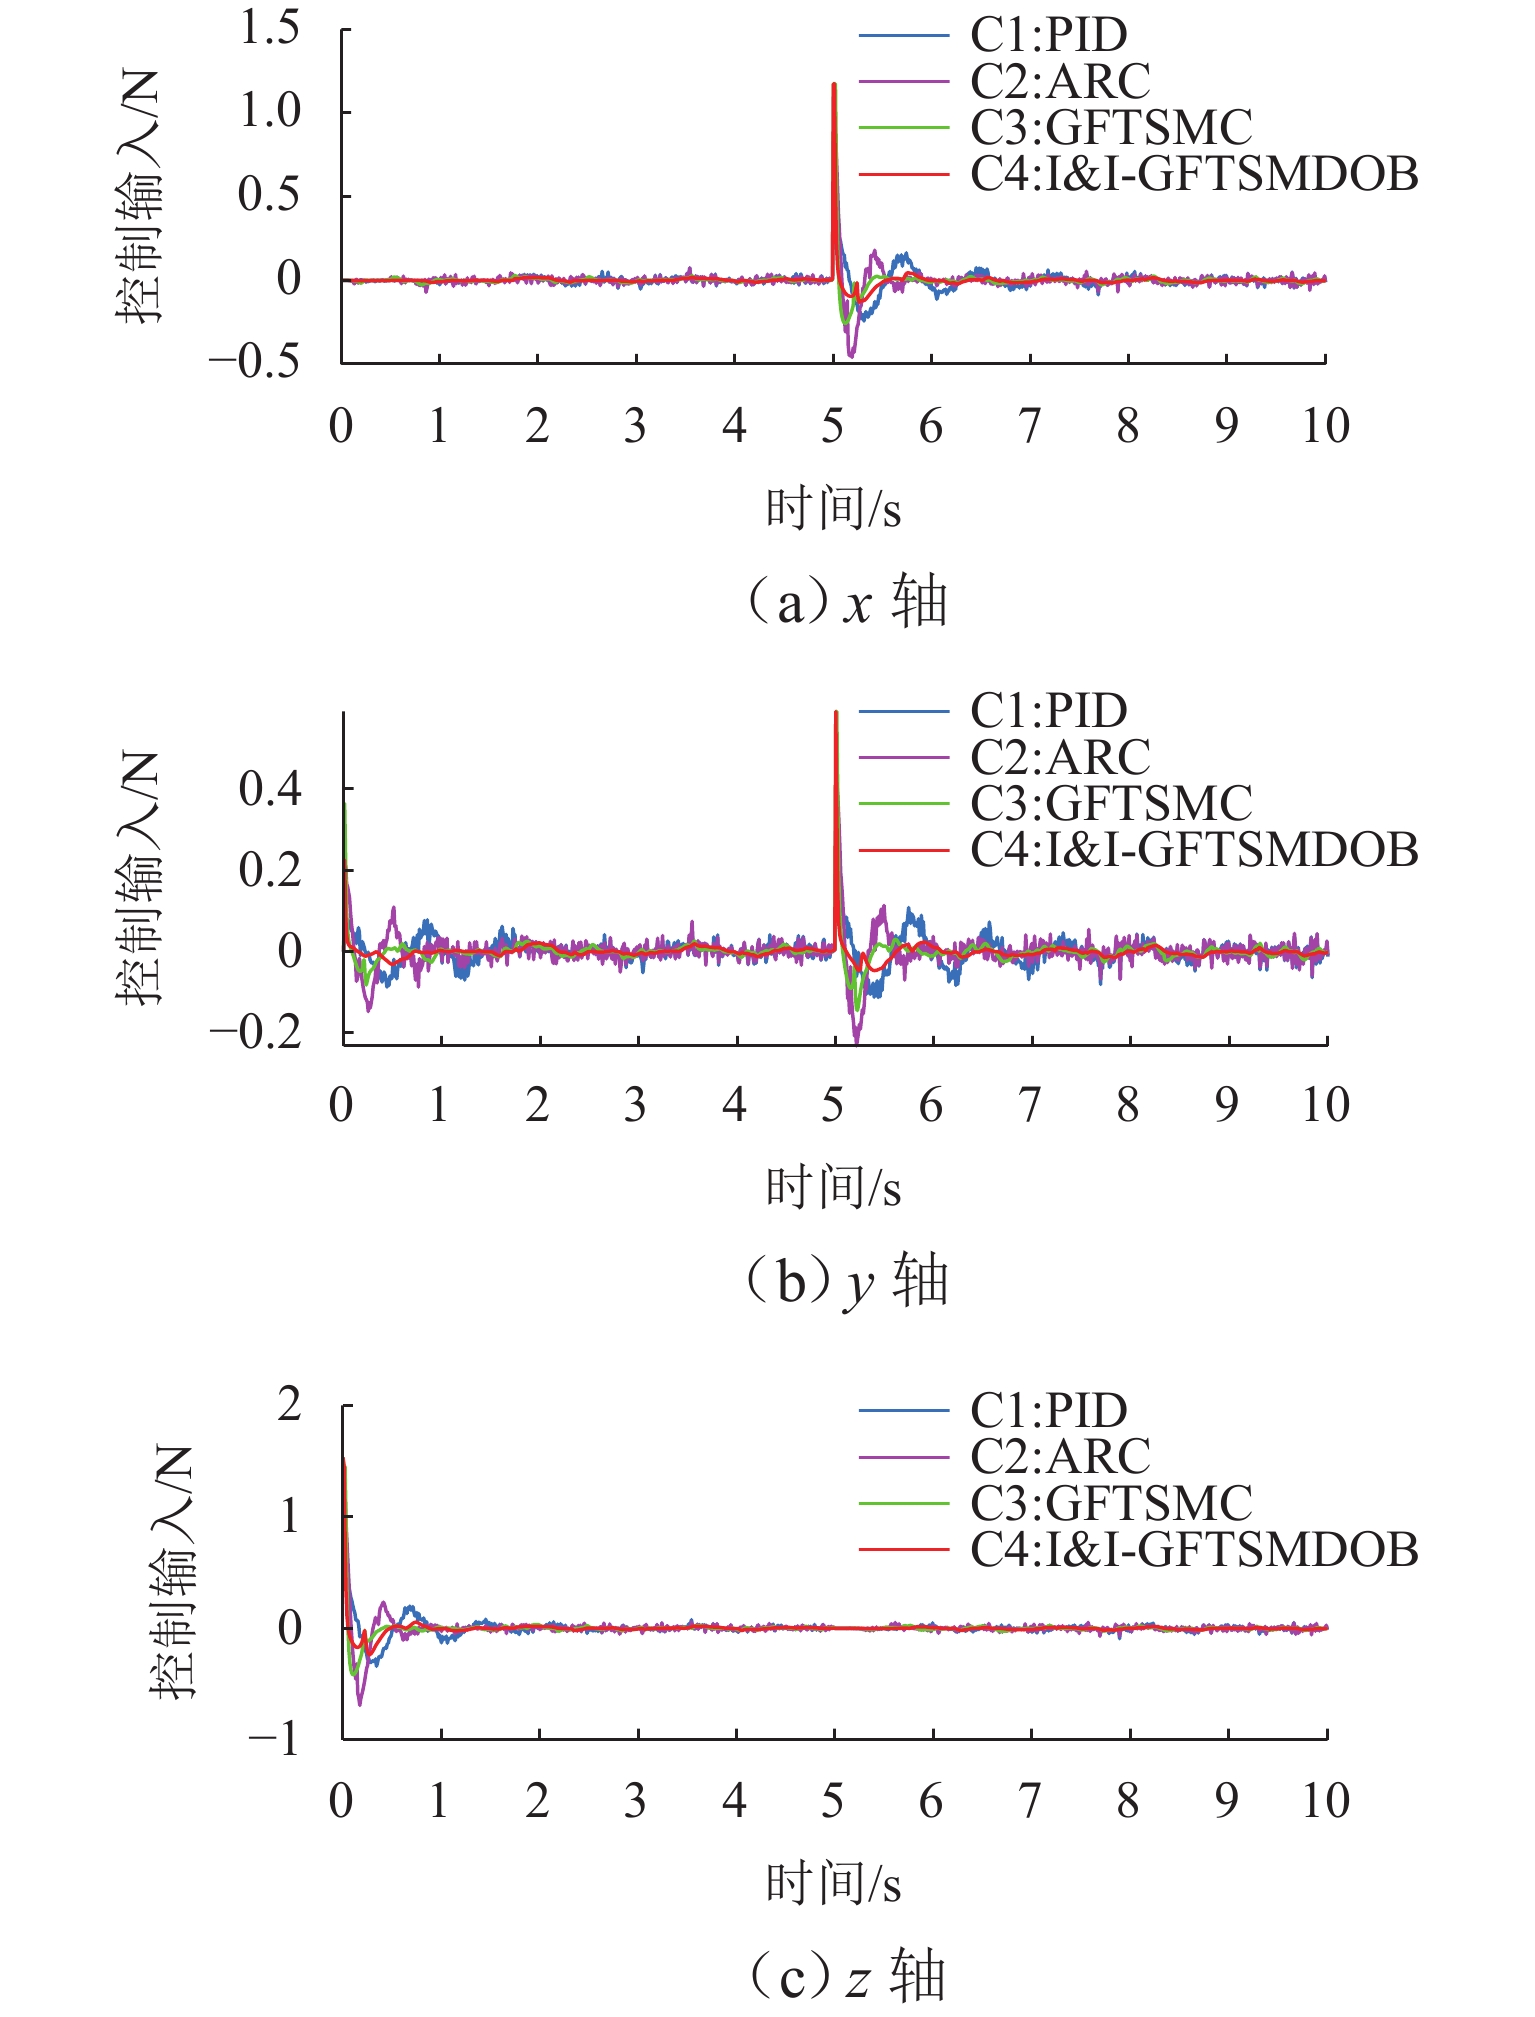
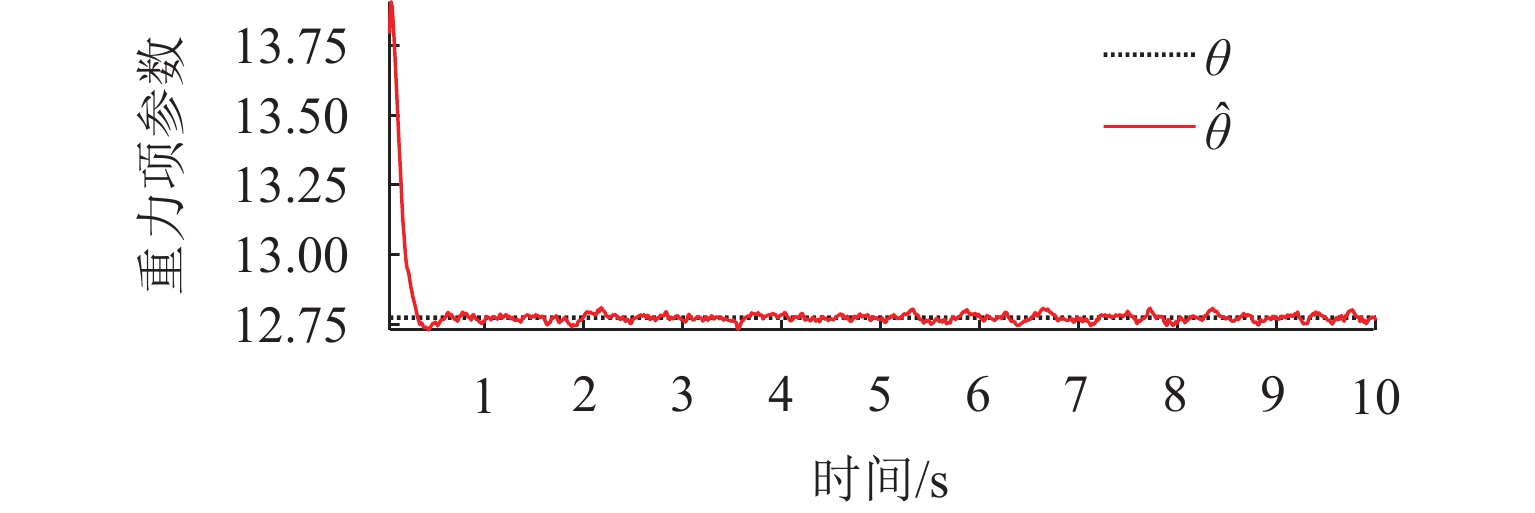
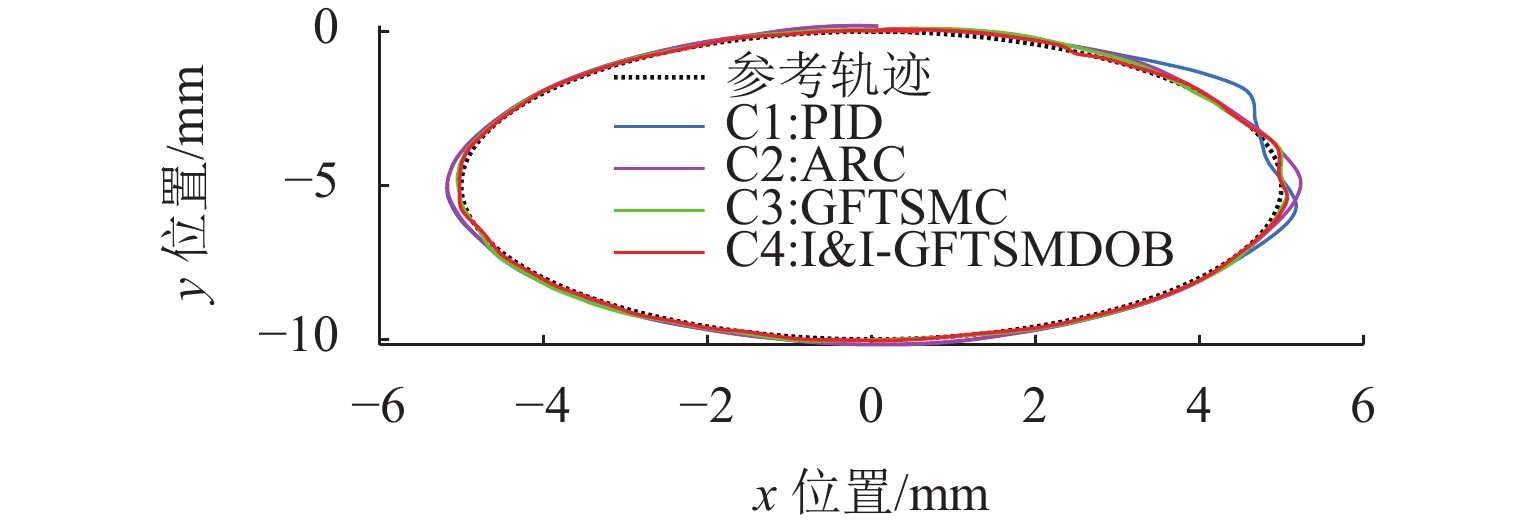
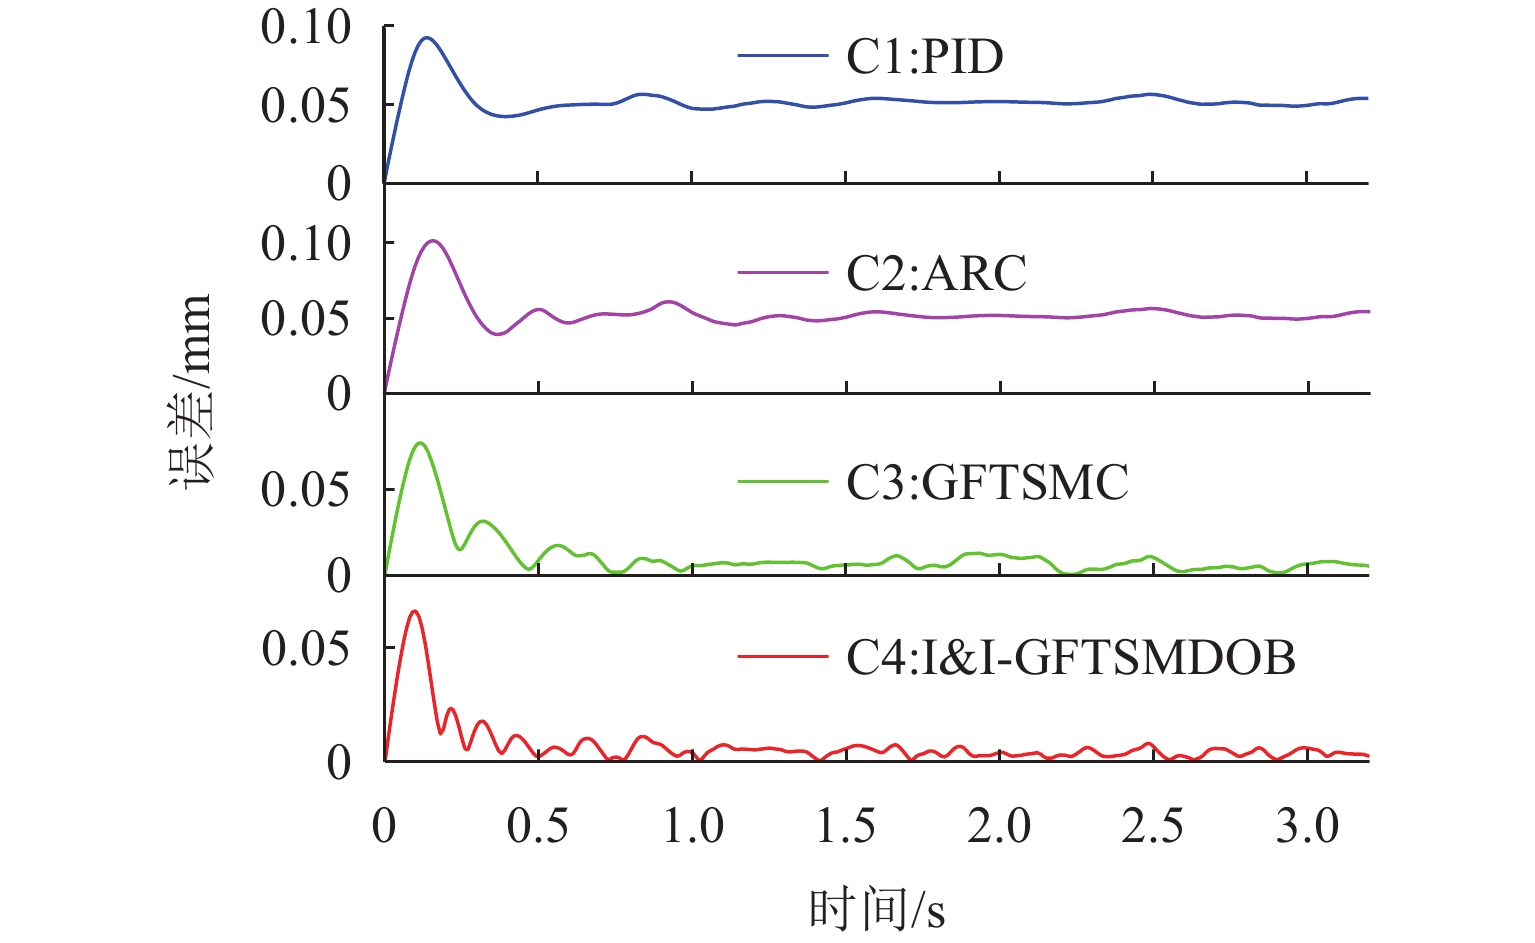
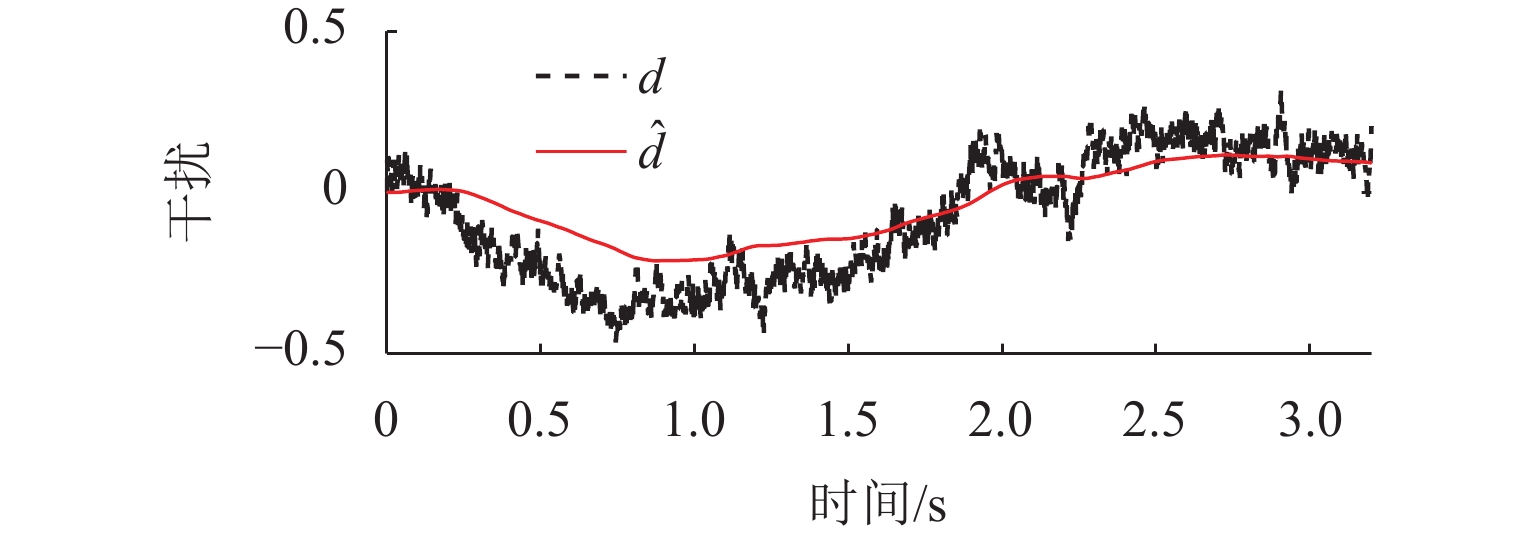
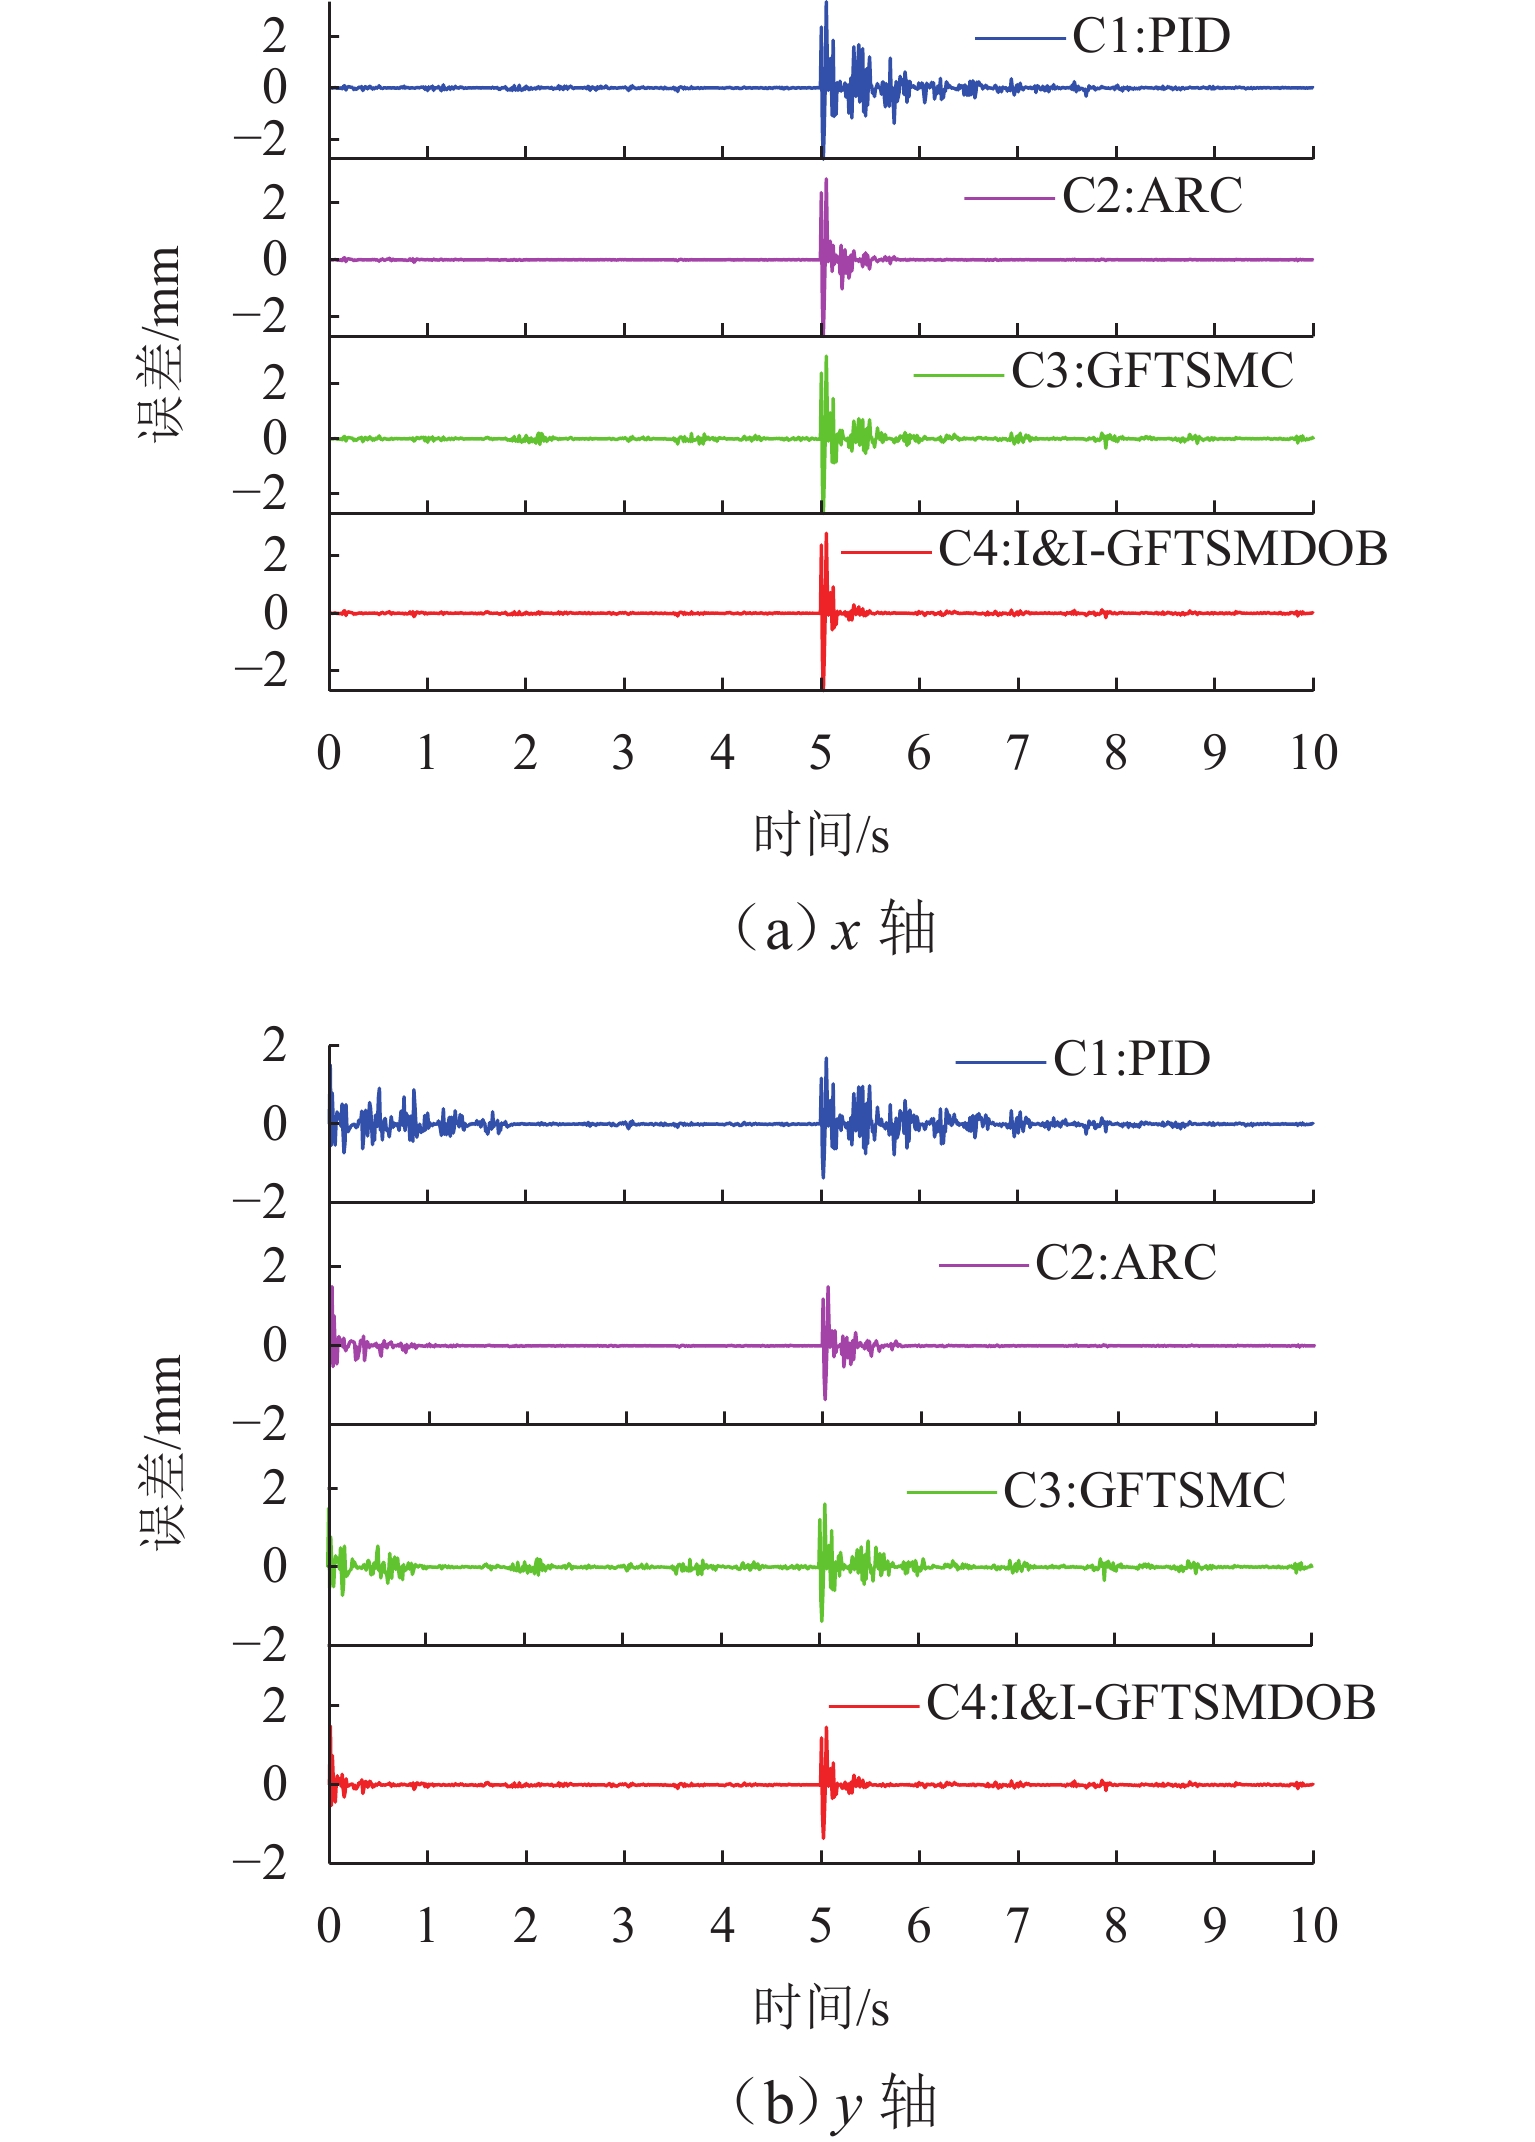
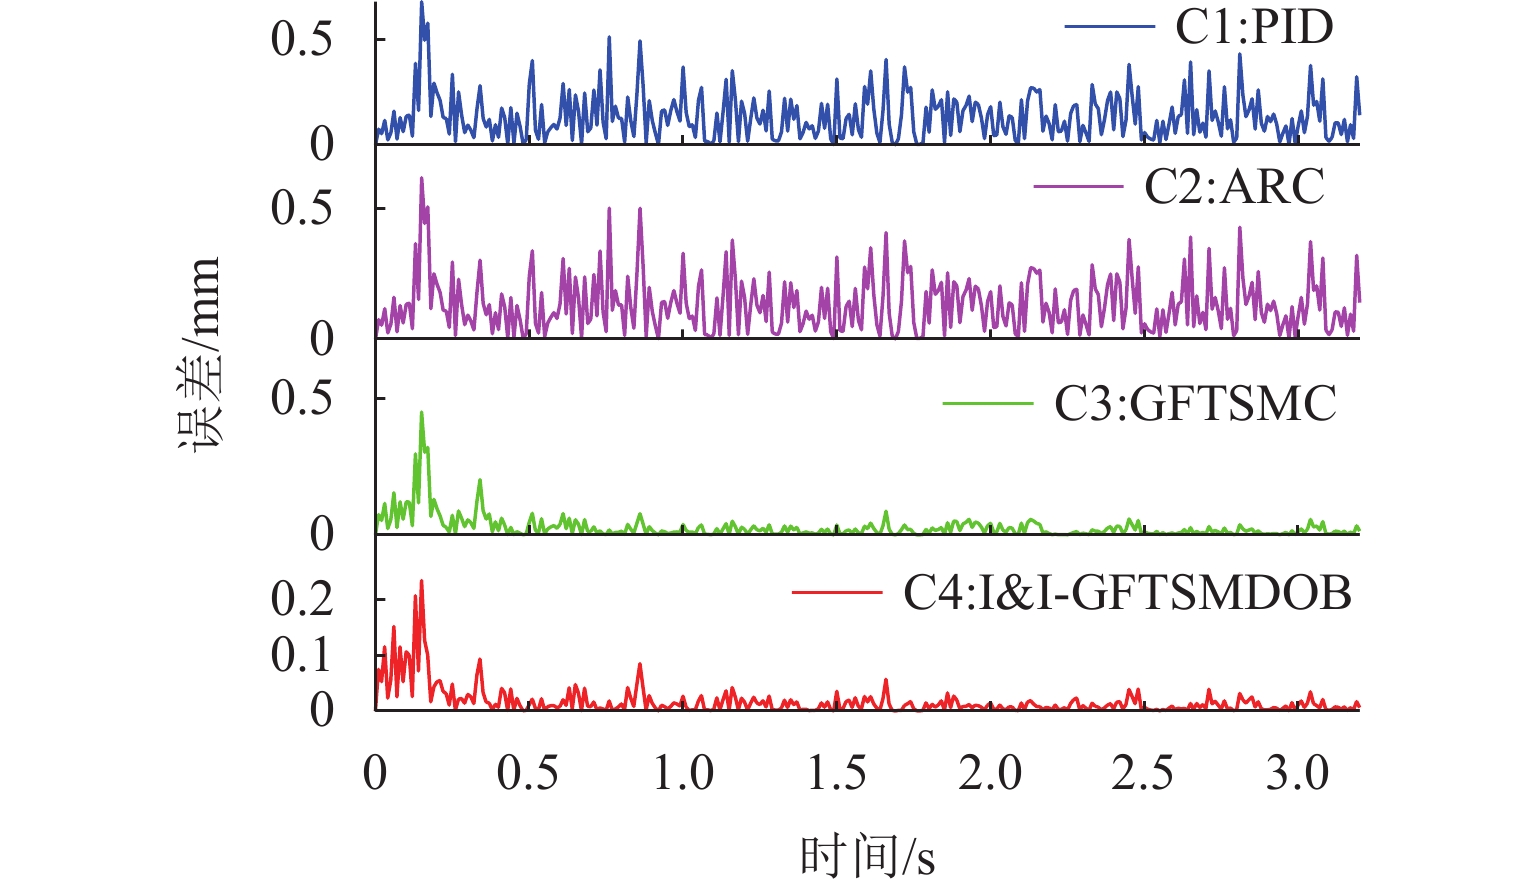
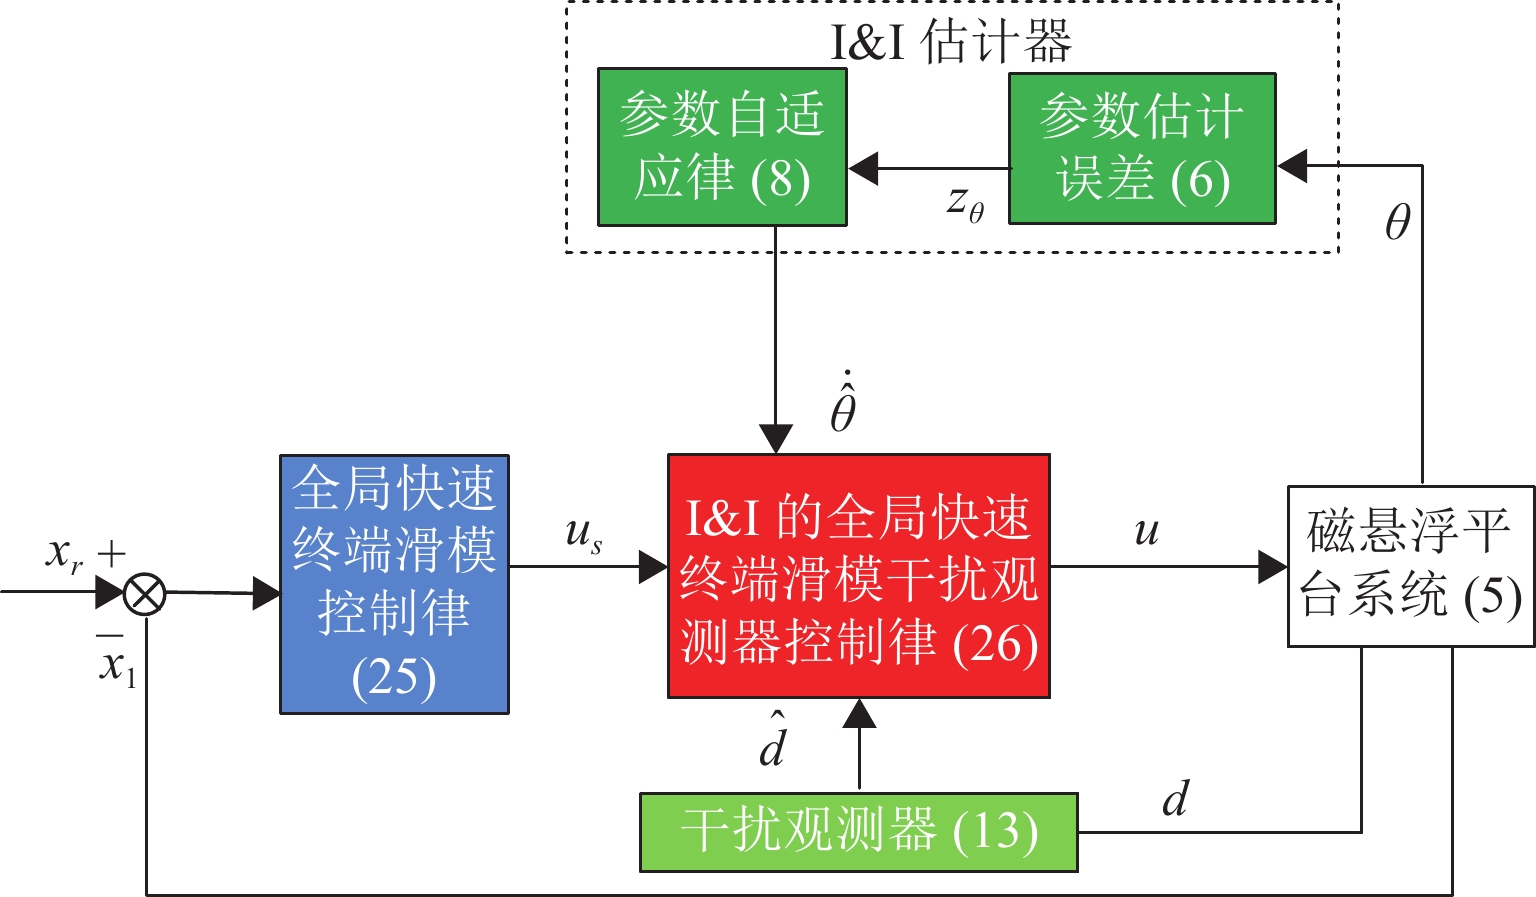
To improve trajectory tracking of a maglev platform under strong nonlinearities, load-parameter uncertainties, and random disturbances, an immersion-and-invariance-based global fast terminal sliding mode control method with a disturbance observer (I&I-GFTSMDOB) was proposed. First, an adaptive estimator was designed to estimate the gravity-term parameter online and provide feedforward compensation. Second, a second-order disturbance observer was constructed to estimate and compensate for random disturbances and unmodeled dynamics. Then, a global fast terminal sliding mode controller with a continuous power reaching law was developed to ensure finite-time convergence and reduce control input chattering. Finally, finite-time convergence and uniform ultimate boundedness of the closed-loop system were established using Lyapunov stability theory. Simulations and experiments were performed to compare the proposed method with PID, adaptive robust control (ARC), and global fast terminal sliding mode control (GFTSMC). The results show that the proposed method achieves smaller tracking errors and smoother control inputs under load variations and random disturbances than the other methods. Compared with PID, the root-mean-square errors of the two horizontal motion axes decrease by about 37.0% and 41.9%, respectively, and the maximum absolute contour error decreases by about 89.3%. Due to the measurement limitations of the experimental platform’s sensors, experimental validation was limited to the control of two horizontal motion axes, while vertical motion performance was further evaluated through simulation. The proposed method provides a theoretical foundation and a practical approach for three-degree-of-freedom levitation control and six-degree-of-freedom high-precision control of maglev platforms.

| [1] |
Liu Y, Li L, Chen S W, et al. 面向IC光刻的超精密运动台控制技术[J]. Laser & Optoelectronics Progress, 2022, 59(9): 0922013.
|
| [2] |
Meng T M, Menq C H. Ultra-precise high-speed untethered manipulation of magnetic scanning microprobe in aqueous solutions[J]. IEEE/ASME Transactions on Mechatronics, 2023, 28(1): 280-291. doi: 10.1109/TMECH.2022.3196596
|
| [3] |
Wu C J, Zhao P Y, Wang Q H, et al. A two-stage collision detection method of a multi-axis CNC machine tool based on bounding box and basic primitive[J]. Precision Engineering, 2025, 93: 177-191. doi: 10.1016/j.precisioneng.2025.01.001
|
| [4] |
Hu J F, Li C, Chen Z, et al. Precision motion control of a 6-DoFs industrial robot with accurate payload estimation[J]. IEEE/ASME Transactions on Mechatronics, 2020, 25(4): 1821-1829. doi: 10.1109/TMECH.2020.2994231
|
| [5] |
Hu C X, Fu H, Zhu Y, et al. A 6-DOF extended unified wrench model for maglev planar motor[J]. IEEE/ASME Transactions on Mechatronics, 2024, 29(5): 3579-3589. doi: 10.1109/TMECH.2024.3349449
|
| [6] |
魏静波, 罗浩, 关子津. 基于干扰观测器的磁悬浮球系统全局快速终端滑模控制[J]. 西南交通大学学报, 2023, 58(4): 836-844. doi: 10.3969/j.issn.0258-2724.20210941
Wei Jingbo, Luo Hao, Guan Zijin. Global fast terminal sliding mode control for maglev ball system based on disturbance observer[J]. Journal of Southwest Jiaotong University, 2023, 58(4): 836-844. doi: 10.3969/j.issn.0258-2724.20210941
|
| [7] |
申璐, 张立伟, 张孟磊. 永磁电磁混合悬浮系统模糊双适应零功率控制[J]. 西南交通大学学报, 2026, 61(4): 1130-1139. doi: 10.3969/j.issn.0258-2724.20240632
Shen Lu, Zhang Liwei, Zhang Menglei. Fuzzy dual-adaptive zero-power control for permanent electromagnetic magnet hybrid suspension system[J]. Journal of Southwest Jiaotong University, 2026, 61(4): 1130-1139. doi: 10.3969/j.issn.0258-2724.20240632
|
| [8] |
Ou T S, Hu C X, Zhu Y, et al. Generation mechanism and decoupling strategy of coupling effect in maglev planar motor[J]. IEEE/ASME Transactions on Mechatronics, 2023, 28(2): 781-791. doi: 10.1109/TMECH.2022.3213561
|
| [9] |
Tomizuka M. Zero phase error tracking algorithm for digital control[J]. Journal of Dynamic Systems, Measurement, and Control, 1987, 109(1): 65-68. doi: 10.1115/1.3143822
|
| [10] |
Rigney B P, Pao L Y, Lawrence D A. Nonminimum phase dynamic inversion for settle time applications[J]. IEEE Transactions on Control Systems Technology, 2009, 17(5): 989-1005. doi: 10.1109/TCST.2008.2002035
|
| [11] |
Butterworth J A, Pao L Y, Abramovitch D Y. The effect of nonminimum-phase zero locations on the performance of feedforward model-inverse control techniques in discrete-time systems[C]//2008 American Control Conference. Seattle: IEEE, 2008: 2696-2702.
|
| [12] |
Hou B Y, Wang Z, Hu C X, et al. Gate recurrent unit neural network based high-precision feedforward control for piezoelectric nanopositioning stage[J]. Engineering Applications of Artificial Intelligence, 2024, 133: 108126. doi: 10.1016/j.engappai.2024.108126
|
| [13] |
Ling J, Feng Z, Chen L, et al. Neural network-based iterative learning control of a piezo-driven nanopositioning stage[J]. Precision Engineering, 2023, 81: 112-123. doi: 10.1016/j.precisioneng.2023.02.006
|
| [14] |
Tsamatsoulis D. Robust enhanced auto-tuning of PID controllers for optimal quality control of cement raw mix via neural networks[J]. ChemEngineering, 2025, 9(3): 52. doi: 10.3390/chemengineering9030052
|
| [15] |
赵磊, 王军晓, 黄光普, 等. 基于扩张状态观测器的磁悬浮球连续滑模控制①[J]. 高技术通讯, 2020, 30(5): 480-486. doi: 10.3772/j.issn.1002-0470.2020.05.006
Zhao Lei, Wang Junxiao, Huang Guangpu, et al. Continuous sliding mode control of magnetic levitation ball based on extended state observer[J]. Chinese High Technology Letters, 2020, 30(5): 480-486. doi: 10.3772/j.issn.1002-0470.2020.05.006
|
| [16] |
靖永志, 贾兴科, 倪胜, 等. 基于扰动补偿的电磁悬浮系统自适应终端滑模控制策略[J]. 西南交通大学学报, 2026, 61(4): 1109-1116. doi: 10.3969/j.issn.0258-2724.20250064
Jing Yongzhi, Jia Xingke, Ni Sheng, et al. Adaptive terminal sliding mode control strategy for electromagnetic levitation system based on disturbance compensation[J]. Journal of Southwest Jiaotong University, 2026, 61(4): 1109-1116. doi: 10.3969/j.issn.0258-2724.20250064
|
| [17] |
孙友刚, 张丹丹, 吉文, 等. 基于模糊补偿的磁浮列车悬浮系统非奇异终端滑模控制[J]. 西南交通大学学报, 2025, 60(4): 803-811. doi: 10.3969/j.issn.0258-2724.20240499
Sun Yougang, Zhang Dandan, Ji Wen, et al. Fuzzy compensation-based non-singular terminal sliding mode control of maglev vehicle levitation system[J]. Journal of Southwest Jiaotong University, 2025, 60(4): 803-811. doi: 10.3969/j.issn.0258-2724.20240499
|
| [18] |
Ou T S, Hu C X, Zhu Y, et al. Advanced LARC strategy of maglev planar motor with GRU neural network prediction[C]//2022 18th IEEE/ASME International Conference on Mechatronic and Embedded Systems and Applications (MESA). Taipei: IEEE, 2022: 1-6.
|
| [19] |
Hu C X, Hu Z P, Zhu Y, et al. Model-data driven learning adaptive robust control of precision mechatronic motion systems with comparative experiments[J]. IEEE Access, 2018, 6: 78286-78296. doi: 10.1109/ACCESS.2018.2884947
|
| [20] |
Chen W H, Yang J, Guo L, et al. Disturbance-observer-based control and related methods: an overview[J]. IEEE Transactions on Industrial Electronics, 2016, 63(2): 1083-1095. doi: 10.1109/TIE.2015.2478397
|
| [21] |
Sariyildiz E. A guide to design disturbance observer-based motion control systems in discrete-time domain[C]//2021 IEEE International Conference on Mechatronics (ICM). Kashiwa: IEEE, 2021: 1-6.
|
| [22] |
Kim W, Suh S. Suboptimal disturbance observer design using all stabilizing Q filter for precise tracking control[J]. Mathematics, 2020, 8(9): 1434. doi: 10.3390/math8091434
|
| [23] |
Yun T H, Kim M J. Disturbance observer with constraints[J]. IEEE Control Systems Letters, 2024, 8: 1949-1954. doi: 10.1109/LCSYS.2024.3418878
|
| [24] |
Du C F, Ming Z F, Ming Y, et al. GRU-ESO strategy for a distributed coil magnetically levitated planar micromotor[J]. Micromachines, 2024, 15(6): 740. doi: 10.3390/mi15060740
|
| [25] |
Jansen J W, Van Lierop C M M, Lomonova E A, et al. Magnetically levitated planar actuator with moving magnets[J]. IEEE Transactions on Industry Applications, 2008, 44(4): 1108-1115. doi: 10.1109/TIA.2008.926065
|
| [26] |
Astolfi A, Ortega R. Immersion and invariance: a new tool for stabilization and adaptive control of nonlinear systems[J]. IEEE Transactions on Automatic Control, 2003, 48(4): 590-606. doi: 10.1109/TAC.2003.809820
|
| [27] |
Khalil H K. Nonlinear Systems[M]. 3rd ed. Upper Saddle River, N. J. : Prentice Hall, 2002.
|
Figures(13) / Tables(5)

 DownLoad: