- ISSN 0258-2724
- CN 51-1277/U
- EI Compendex
- Scopus
- Indexed by Core Journals of China, Chinese S&T Journal Citation Reports
- Chinese S&T Journal Citation Reports
- Chinese Science Citation Database
| Citation: | XUE Xiaoqiang, WANG Xiaoyong, LIU Wei, CHE Jian, SHEN Xiaolong, CHEN He. Regulation Control of Flexible Manipulators with Unknown Parameters[J]. Journal of Southwest Jiaotong University. doi: 10.3969/j.issn.0258-2724.20250270

|
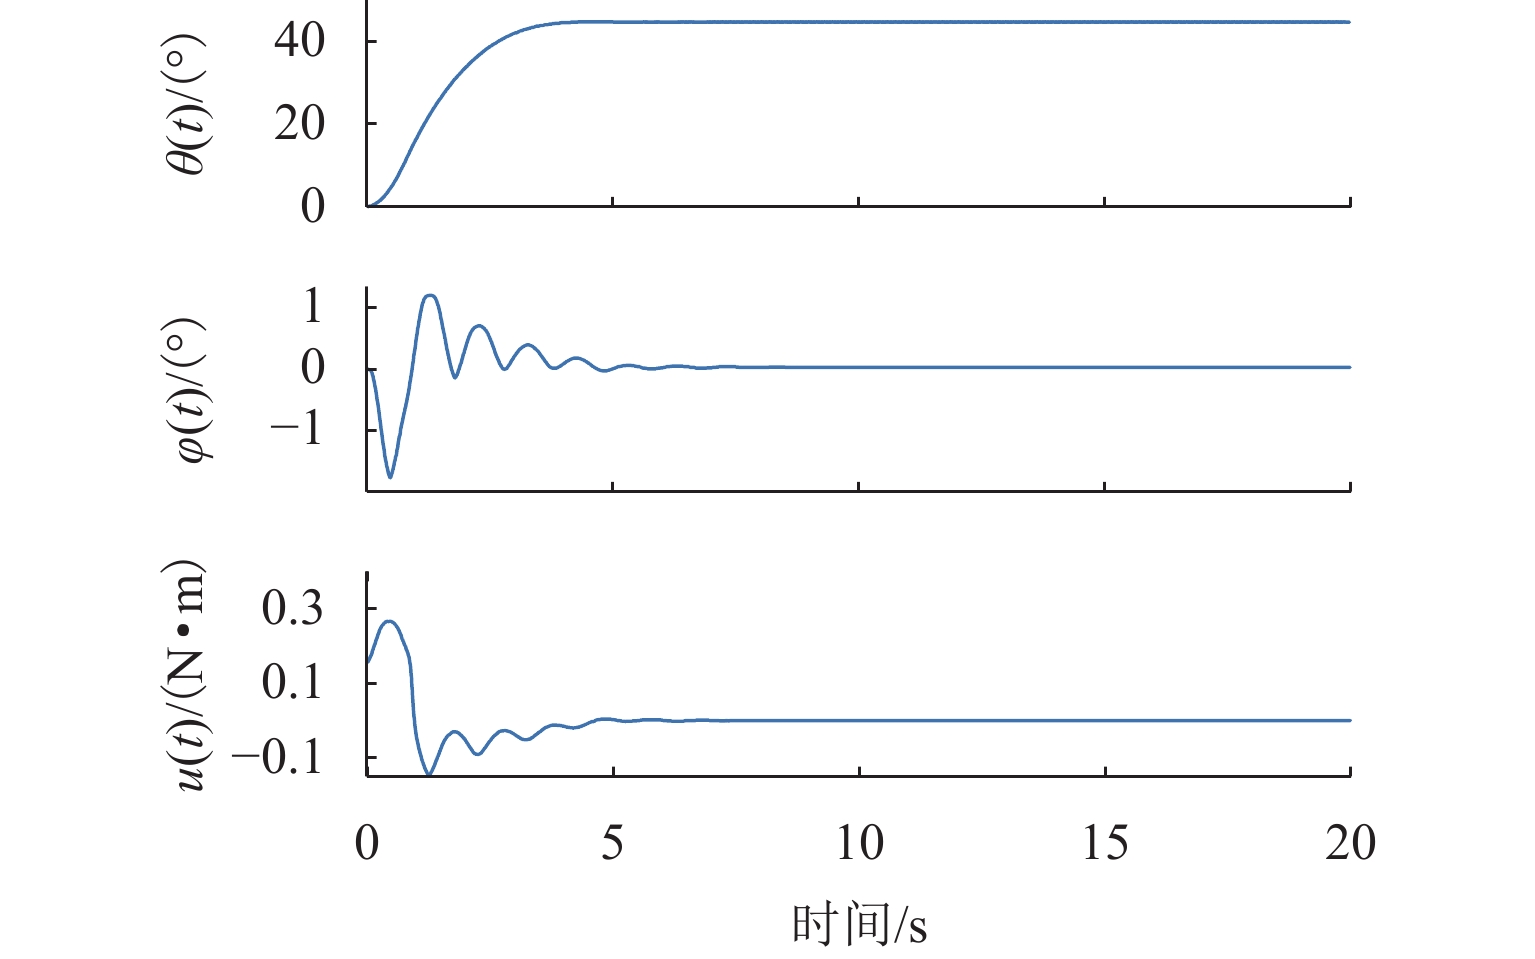
With the rapid development of industrial automation and intelligent manufacturing, flexible manipulators have been widely used in the aerospace and precision instrument manufacturing industries. To address the challenges of achieving precise positioning and suppressing vibrations in flexible manipulators with unknown parameters, a sliding mode control method based on a time-delay estimator (TDE) is proposed. First, the dynamic characteristics of the system are analyzed and the dynamic model is established. On this basis, a sliding mode controller is designed, and the unknown system dynamics are estimated by using a time-delay estimator. Furthermore, to enhance the system’s control performance, a term for suppressing the load deflection angle is incorporated into the control law to effectively reduce the effects of flexible vibrations. Subsequently, a rigorous stability analysis of the closed-loop system is conducted, and the convergence of the system state variables is proved. Finally, simulation experiments were conducted to verify the effectiveness of the proposed method. The results show that the proposed control method can achieve accurate positioning while effectively suppressing flexible vibrations.

| [1] |
Zhou Q, Zhao S Y, Li H Y, et al. Adaptive neural network tracking control for robotic manipulators with dead zone[J]. IEEE Transactions on Neural Networks and Learning Systems, 2019, 30(12): 3611-3620. doi: 10.1109/TNNLS.2018.2869375
|
| [2] |
江海凡, 丁国富, 肖通, 等. 数字孪生演进模型及其在智能制造中的应用[J]. 西南交通大学学报, 2022, 57(6): 1386-1394. doi: 10.3969/j.issn.0258-2724.20210202
Jiang Haifan, Ding Guofu, Xiao Tong, et al. Digital twin evolution model and its applications in intelligent manufacturing[J]. Journal of Southwest Jiaotong University, 2022, 57(6): 1386-1394. doi: 10.3969/j.issn.0258-2724.20210202
|
| [3] |
Chen H, Sun N. Nonlinear control of underactuated systems subject to both actuated and unactuated state constraints with experimental verification[J]. IEEE Transactions on Industrial Electronics, 2020, 67(9): 7702-7714. doi: 10.1109/TIE.2019.2946541
|
| [4] |
Yang T, Sun N, Fang Y C. Neuroadaptive control for complicated underactuated systems with simultaneous output and velocity constraints exerted on both actuated and unactuated states[J]. IEEE Transactions on Neural Networks and Learning Systems, 2023, 34(8): 4488-4498. doi: 10.1109/TNNLS.2021.3115960
|
| [5] |
Yang T, Sun N, Chen H, et al. Adaptive optimal motion control of uncertain underactuated mechatronic systems with actuator constraints[J]. IEEE/ASME Transactions on Mechatronics, 2023, 28(1): 210-222. doi: 10.1109/TMECH.2022.3192002
|
| [6] |
Deng H, Sun J D, Huang S D, et al. Vibration suppression of the flexible manipulator using optimal input shaper and linear quadratic regulator[C]//2015 12th International Conference on Ubiquitous Robots and Ambient Intelligence (URAI). Goyang. IEEE, 2015: 255-260.
|
| [7] |
Lou J Q, Liao J J, Wei Y D, et al. Experimental identification and vibration control of a piezoelectric flexible manipulator using optimal multi-poles placement control[J]. Applied Sciences, 2017, 7(3): 309. doi: 10.3390/app7030309
|
| [8] |
Jiang T T, Liu J K, He W. Boundary control for a flexible manipulator based on infinite dimensional disturbance observer[J]. Journal of Sound and Vibration, 2015, 348: 1-14.
|
| [9] |
Cao F F, Liu J K. An adaptive iterative learning algorithm for boundary control of a coupled ODE–PDE two-link rigid–flexible manipulator[J]. Journal of the Franklin Institute, 2017, 354(1): 277-297. doi: 10.1016/j.jfranklin.2016.10.013
|
| [10] |
Zhao Z J, Ahn C K. Boundary antisaturation vibration control design for a flexible Timoshenko robotic manipulator[J]. International Journal of Robust and Nonlinear Control, 2020, 30(3): 1098-1114. doi: 10.1002/rnc.4810
|
| [11] |
Dubay R, Hassan M, Li C Y, et al. Finite element based model predictive control for active vibration suppression of a one-link flexible manipulator[J]. ISA Transactions, 2014, 53(5): 1609-1619. doi: 10.1016/j.isatra.2014.05.023
|
| [12] |
Pradhan S K, Subudhi B. Nonlinear adaptive model predictive controller for a flexible manipulator: an experimental study[J]. IEEE Transactions on Control Systems Technology, 2014, 22(5): 1754-1768. doi: 10.1109/TCST.2013.2294545
|
| [13] |
Pedro J O, Tshabalala T. Hybrid NNMPC/PID control of a two-link flexible manipulator with actuator dynamics[C]//2015 10th Asian Control Conference (ASCC). Kota Kinabalu, Malaysia. IEEE, 2015: 1-6.
|
| [14] |
Zhang S, Zhang Y, Zhang X, et al. Fuzzy PID control of a two-link flexible manipulator[J]. Journal of Vibroengineering, 2016, 18(1): 250-266. doi: 10.21595/jve.2015.16266
|
| [15] |
靖永志, 冯伟, 王森, 等. 基于自适应非奇异终端滑模的悬浮控制策略[J]. 西南交通大学学报, 2022, 57(3): 566-573. doi: 10.3969/j.issn.0258-2724.20210743
Jing Yongzhi, Feng Wei, Wang Sen, et al. Levitation control strategy based on adaptive non-singular terminal sliding mode[J]. Journal of Southwest Jiaotong University, 2022, 57(3): 566-573. doi: 10.3969/j.issn.0258-2724.20210743
|
| [16] |
Chang W M, Tong S C, Li Y M. Adaptive fuzzy backstepping output constraint control of flexible manipulator with actuator saturation[J]. Neural Computing and Applications, 2017, 28(S1): 1165-1175. doi: 10.1007/s00521-016-2425-2
|
| [17] |
杨昕然, 陈鹤. 具有参数不确定性的2D TORA系统振动抑制控制[J]. 河北工业大学学报, 2024, 53(5): 68-75. doi: 10.14081/j.cnki.hgdxb.2024.05.008
Yang Xinran, Chen He. Vibration suppression control for 2D TORA systems with parametric uncertainties[J]. Journal of Hebei University of Technology, 2024, 53(5): 68-75. doi: 10.14081/j.cnki.hgdxb.2024.05.008
|
| [18] |
Li H Y, Zhao S Y, He W, et al. Adaptive finite-time tracking control of full state constrained nonlinear systems with dead-zone[J]. Automatica, 2019, 100: 99-107. doi: 10.1016/j.automatica.2018.10.030
|
| [19] |
Tang Y G, Sun F C, Sun Z Q. Neural network control of flexible-link manipulators using sliding mode[J]. Neurocomputing, 2006, 70(1/2/3): 288-295. doi: 10.1016/j.neucom.2006.01.030
|
| [20] |
Sun C Y, Gao H J, He W, et al. Fuzzy neural network control of a flexible robotic manipulator using assumed mode method[J]. IEEE Transactions on Neural Networks and Learning Systems, 2018, 29(11): 5214-5227. doi: 10.1109/TNNLS.2017.2743103
|
| [21] |
Qiu Z C, Li C, Zhang X M. Experimental study on active vibration control for a kind of two-link flexible manipulator[J]. Mechanical Systems and Signal Processing, 2019, 118: 623-644. doi: 10.1016/j.ymssp.2018.09.001
|
| [22] |
Cheng W S. Neural-fuzzy control of a flexible dynamic tracking and adjusting manipulator[J]. Transactions of the Institute of Measurement and Control, 2015, 37(7): 883-891. doi: 10.1177/0142331213510549
|
| [23] |
Sun W, Su S F, Xia J W, et al. Adaptive fuzzy tracking control of flexible-joint robots with full-state constraints[J]. IEEE Transactions on Systems, Man, and Cybernetics: Systems, 2019, 49(11): 2201-2209. doi: 10.1109/TSMC.2018.2870642
|
| [24] |
Islam S, Liu X P. Robust sliding mode control for robot manipulators[J]. IEEE Transactions on Industrial Electronics, 2011, 58(6): 2444-2453. doi: 10.1109/TIE.2010.2062472
|
| [25] |
Man Z H, Paplinski A P, Wu H R. A robust MIMO terminal sliding mode control scheme for rigid robotic manipulators[J]. IEEE Transactions on Automatic Control, 1994, 39(12): 2464-2469. doi: 10.1109/9.362847
|
| [26] |
Yu S H, Yu X H, Shirinzadeh B, et al. Continuous finite-time control for robotic manipulators with terminal sliding mode[J]. Automatica, 2005, 41(11): 1957-1964. doi: 10.1016/j.automatica.2005.07.001
|
| [27] |
Bingi K, Prusty B R, Pal Singh A. A review on fractional-order modelling and control of robotic manipulators[J]. Fractal and Fractional, 2023, 7(1): 77. doi: 10.3390/fractalfract7010077
|
| [28] |
Bazaei A, Majd V J. Neuro-adaptive friction compensation for single-link flexible robots using serial-gray-box modeling strategy[J]. Journal of Dynamic Systems, Measurement, and Control, 2006, 128(2): 297-306. doi: 10.1115/1.2192838
|
| [29] |
Jung S, Hsia T C, Bonitz R G. Force tracking impedance control of robot manipulators under unknown environment[J]. IEEE Transactions on Control Systems Technology, 2004, 12(3): 474-483. doi: 10.1109/TCST.2004.824320
|
| [30] |
Yao M B, Xiao X M, Tian Y, et al. A fast terminal sliding mode control scheme with time-varying sliding mode surfaces[J]. Journal of the Franklin Institute, 2021, 358(10): 5386-5407. doi: 10.1016/j.jfranklin.2021.05.006
|
| [31] |
Feng Y, Yu X H, Man Z H. Non-singular terminal sliding mode control of rigid manipulators[J]. Automatica, 2002, 38(12): 2159-2167. doi: 10.1016/S0005-1098(02)00147-4
|
| [32] |
Yang L, Yang J Y. Nonsingular fast terminal sliding-mode control for nonlinear dynamical systems[J]. International Journal of Robust and Nonlinear Control, 2011, 21(16): 1865-1879. doi: 10.1002/rnc.1666
|
| [33] |
Owen D B, Abramowitz M, Stegun I A. Handbook of mathematical functions with formulas, graphs, and mathematical tables[J]. Technometrics, 1965, 7(1): 78. doi: 10.2307/1266136
|
| [34] |
Sun N, Fang Y C, Chen H, et al. Nonlinear stabilizing control for ship-mounted cranes with ship roll and heave movements: design, analysis, and experiments[J]. IEEE Transactions on Systems, Man, and Cybernetics: Systems, 2018, 48(10): 1781-1793. doi: 10.1109/TSMC.2017.2700393
|
Figures(6)

 DownLoad: