- ISSN 0258-2724
- CN 51-1277/U
- EI Compendex
- Scopus
- Indexed by Core Journals of China, Chinese S&T Journal Citation Reports
- Chinese S&T Journal Citation Reports
- Chinese Science Citation Database
| Citation: | FENG Tingwei, YANG Da, LIU Jiawei, LIANG Hongbin. Detection Method for Entire Vehicle Lane-Changing Process Based on Multi-Source Time-Series Data Fusion[J]. Journal of Southwest Jiaotong University. doi: 10.3969/j.issn.0258-2724.20240566

|
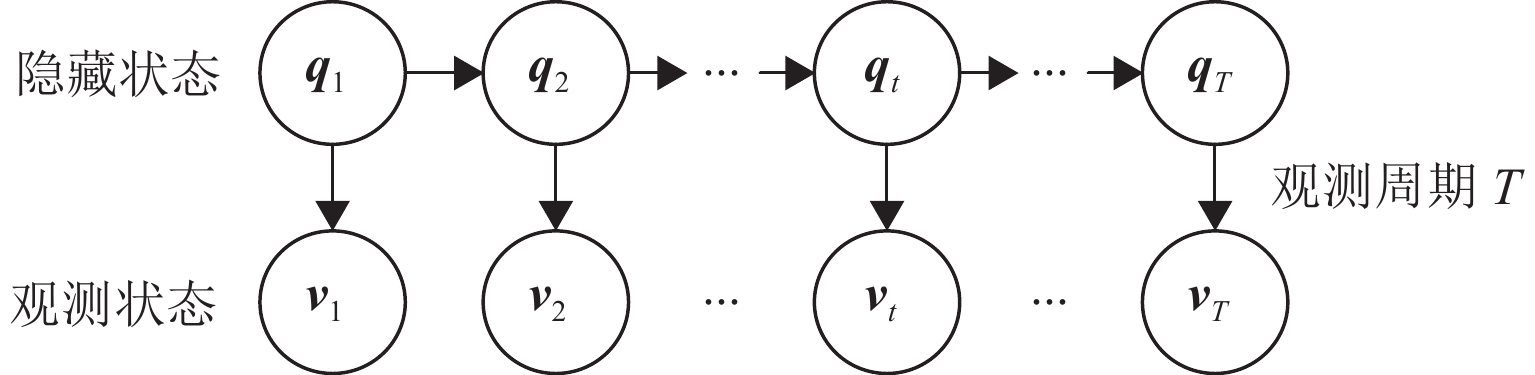
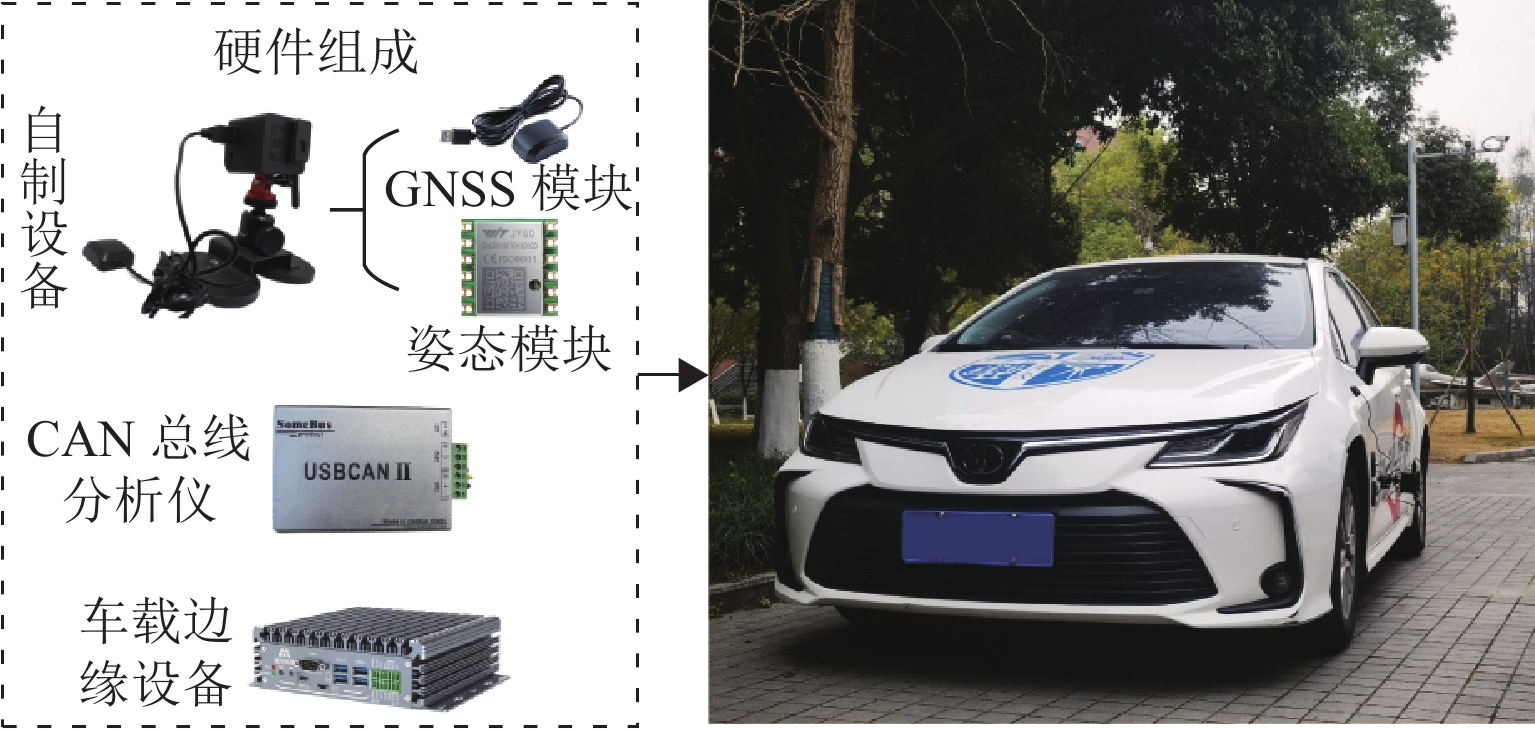
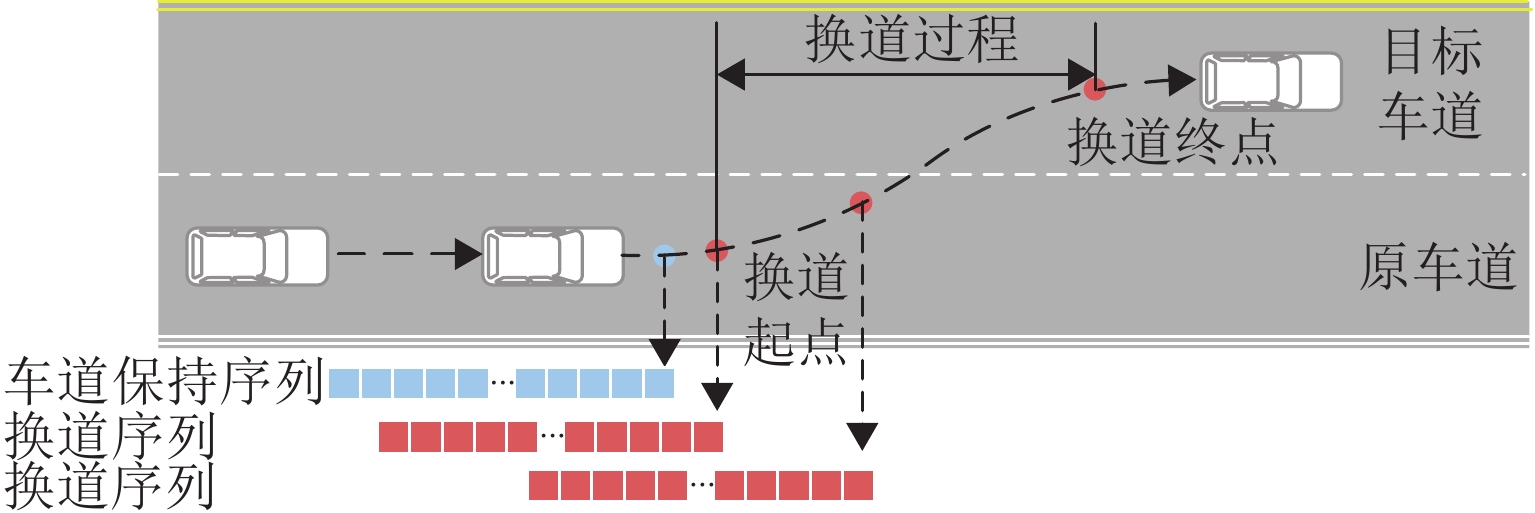
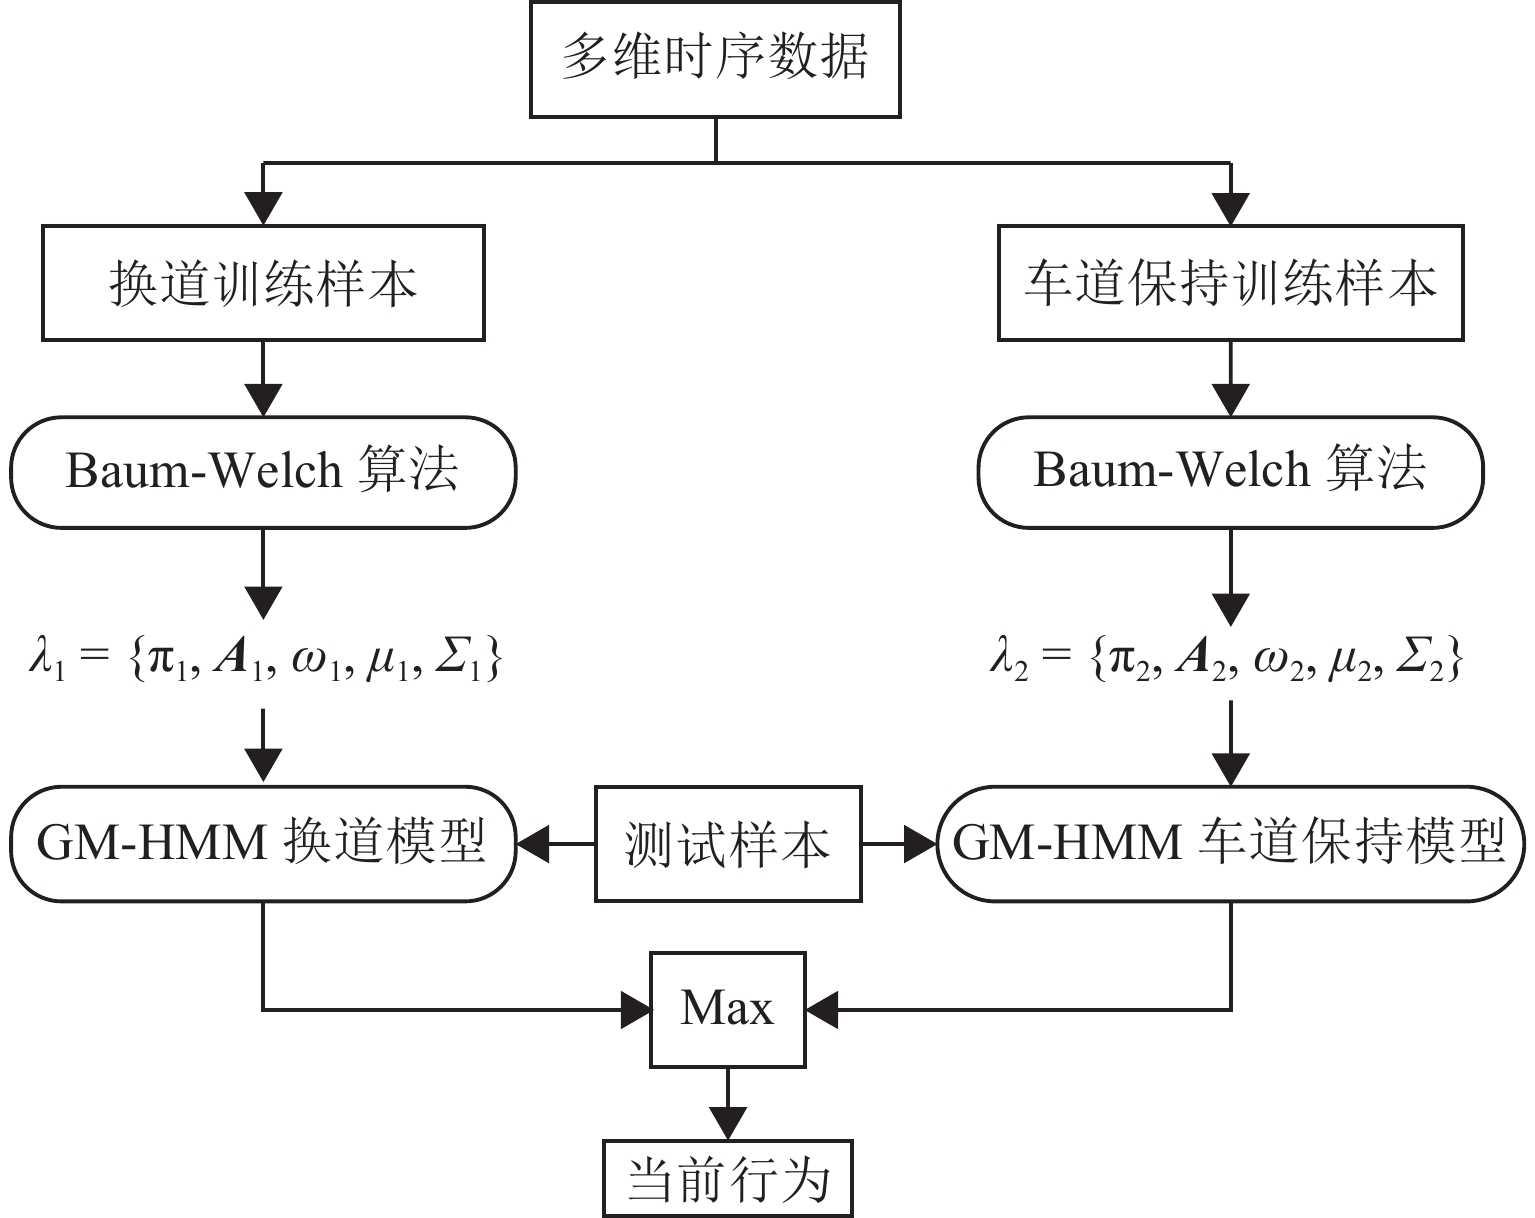
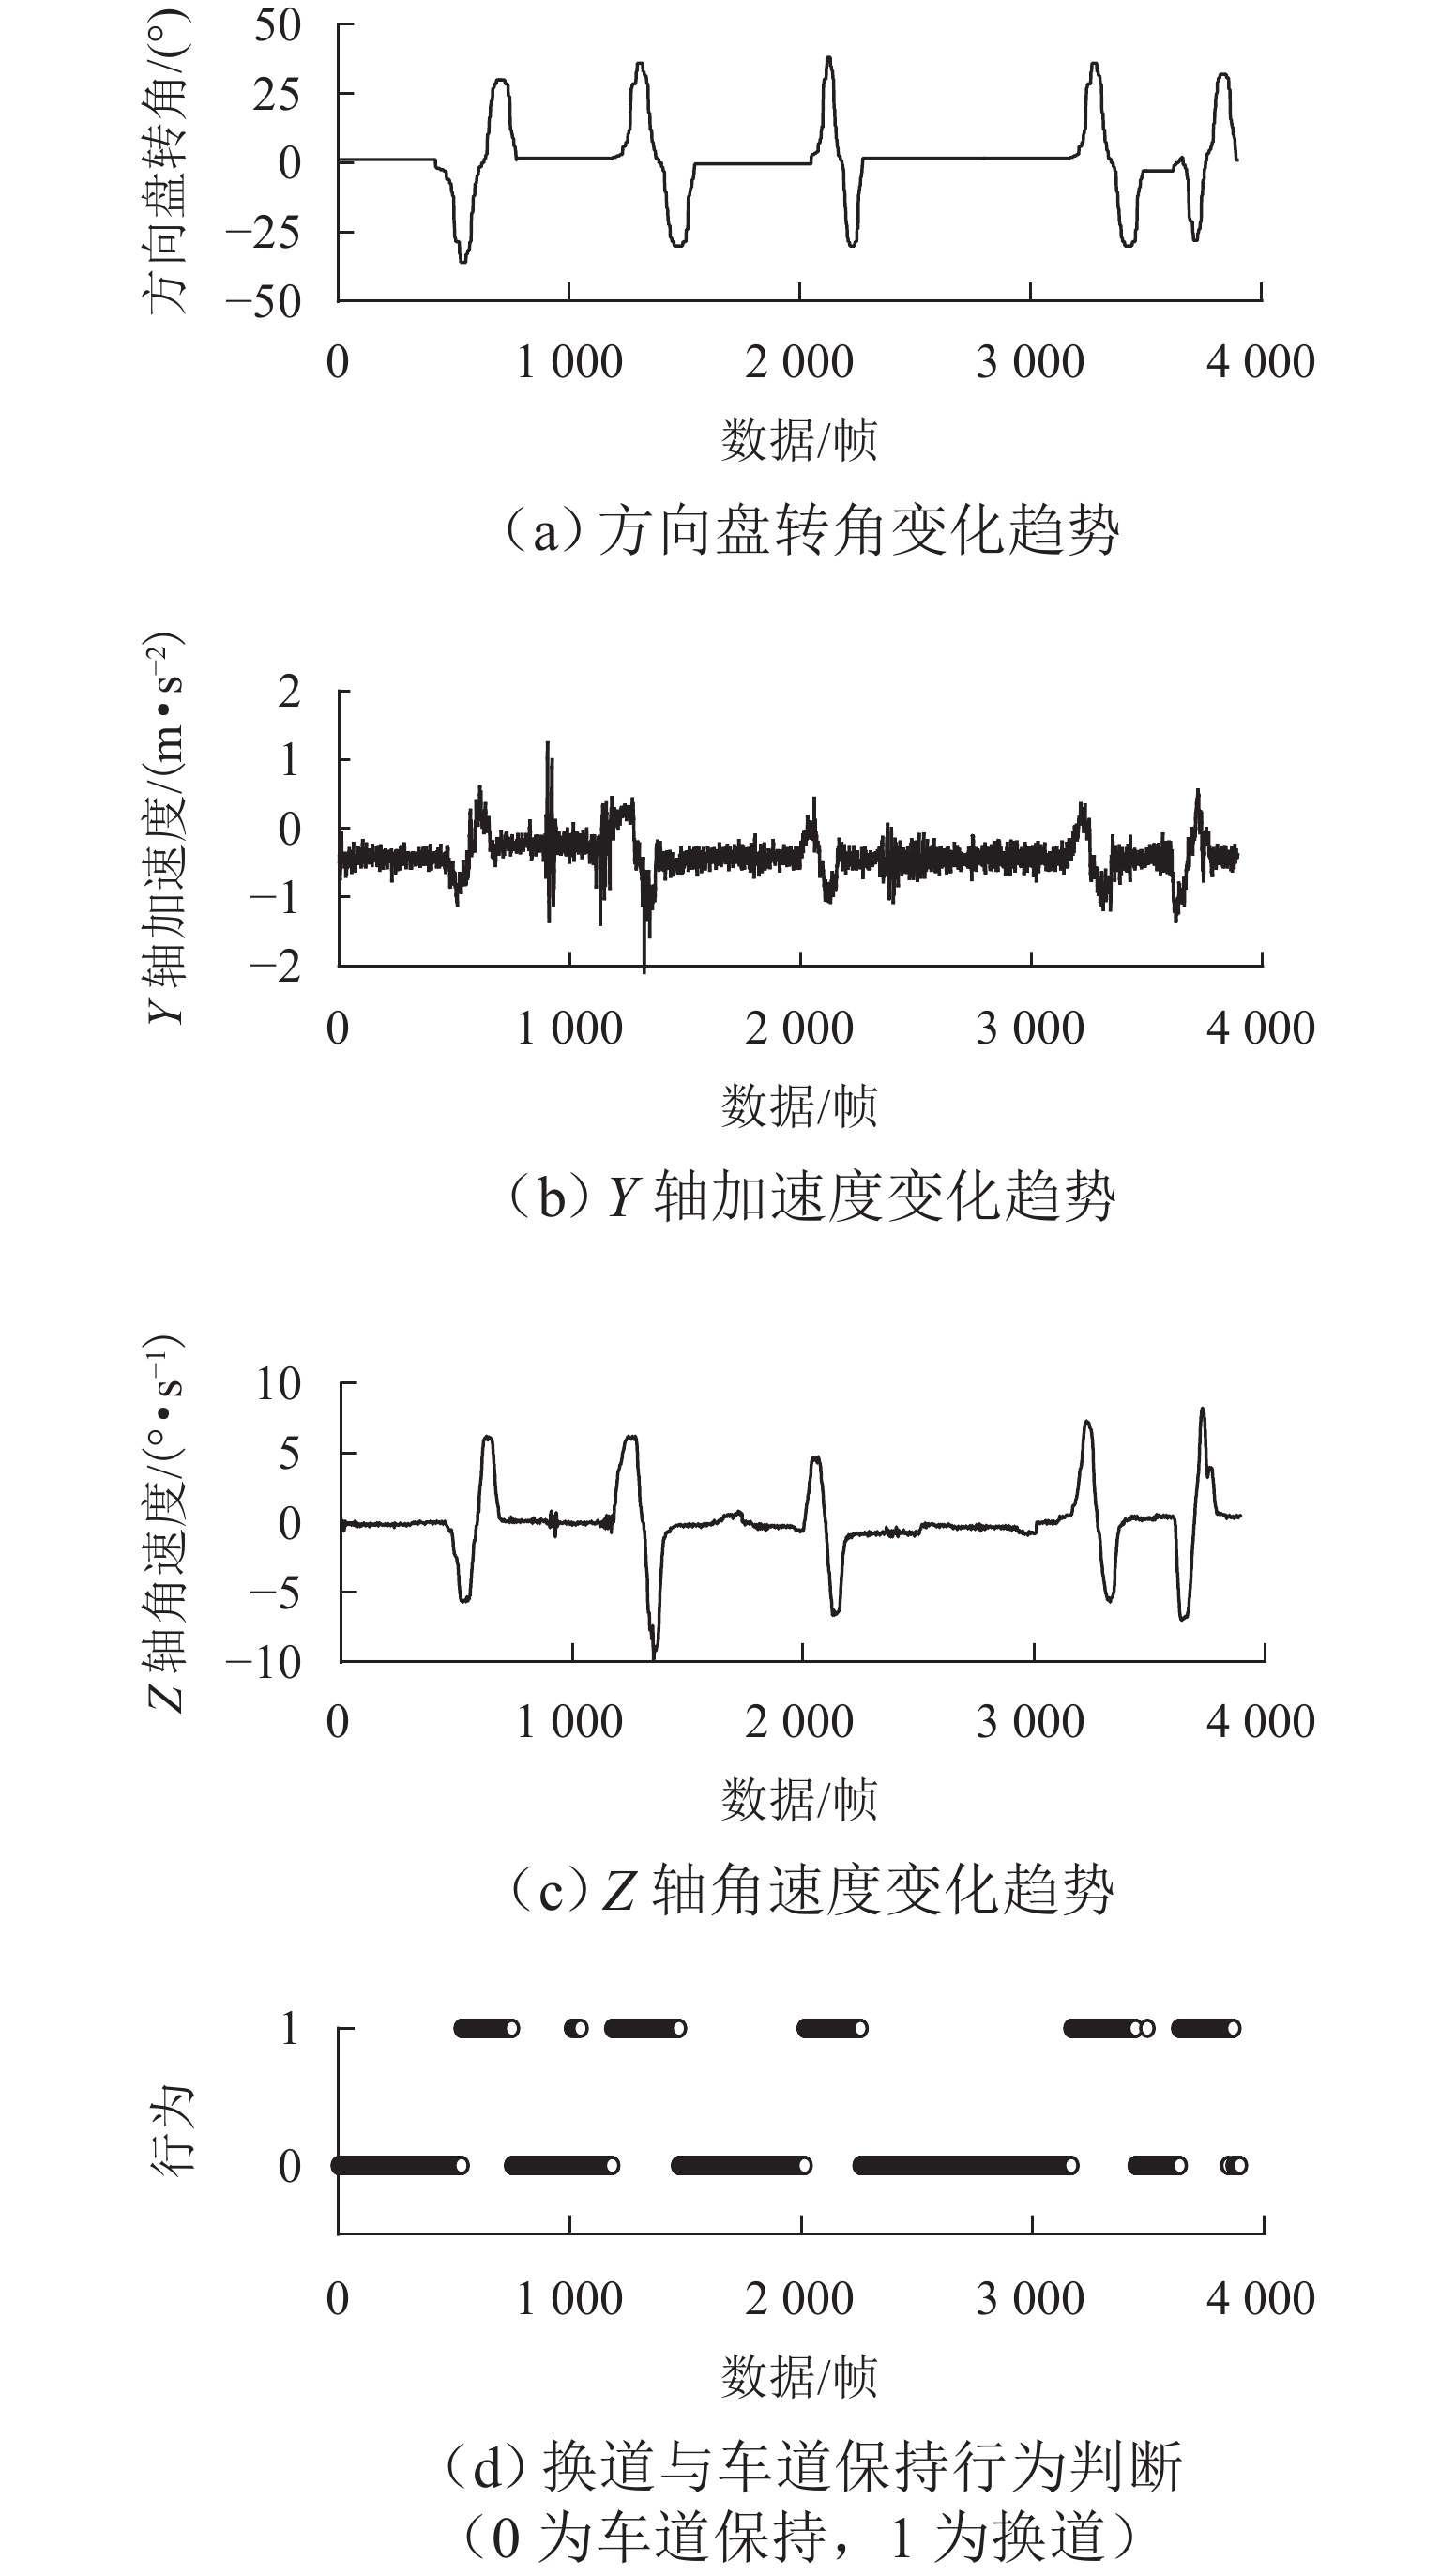
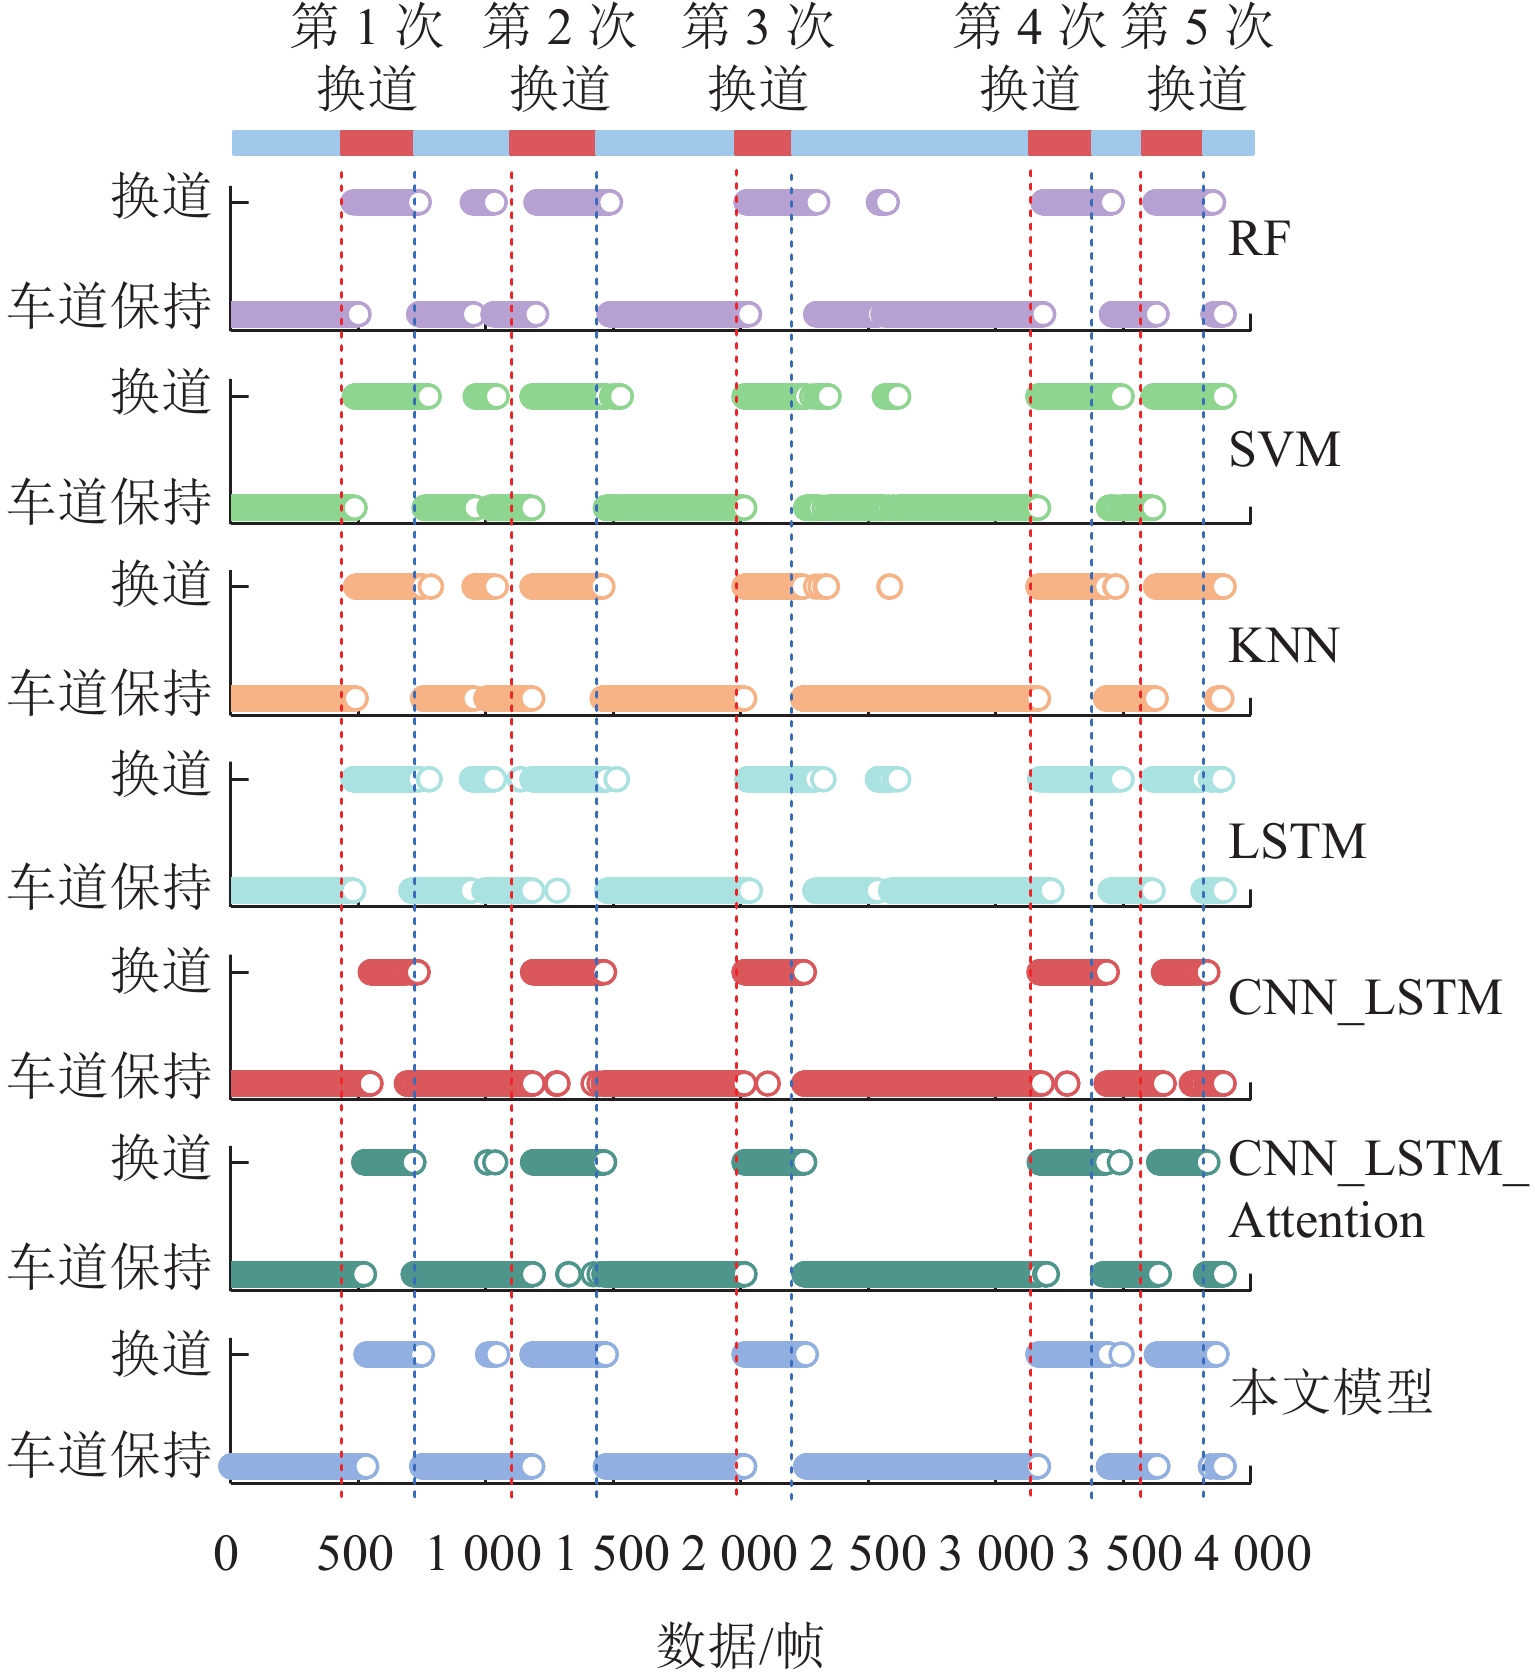
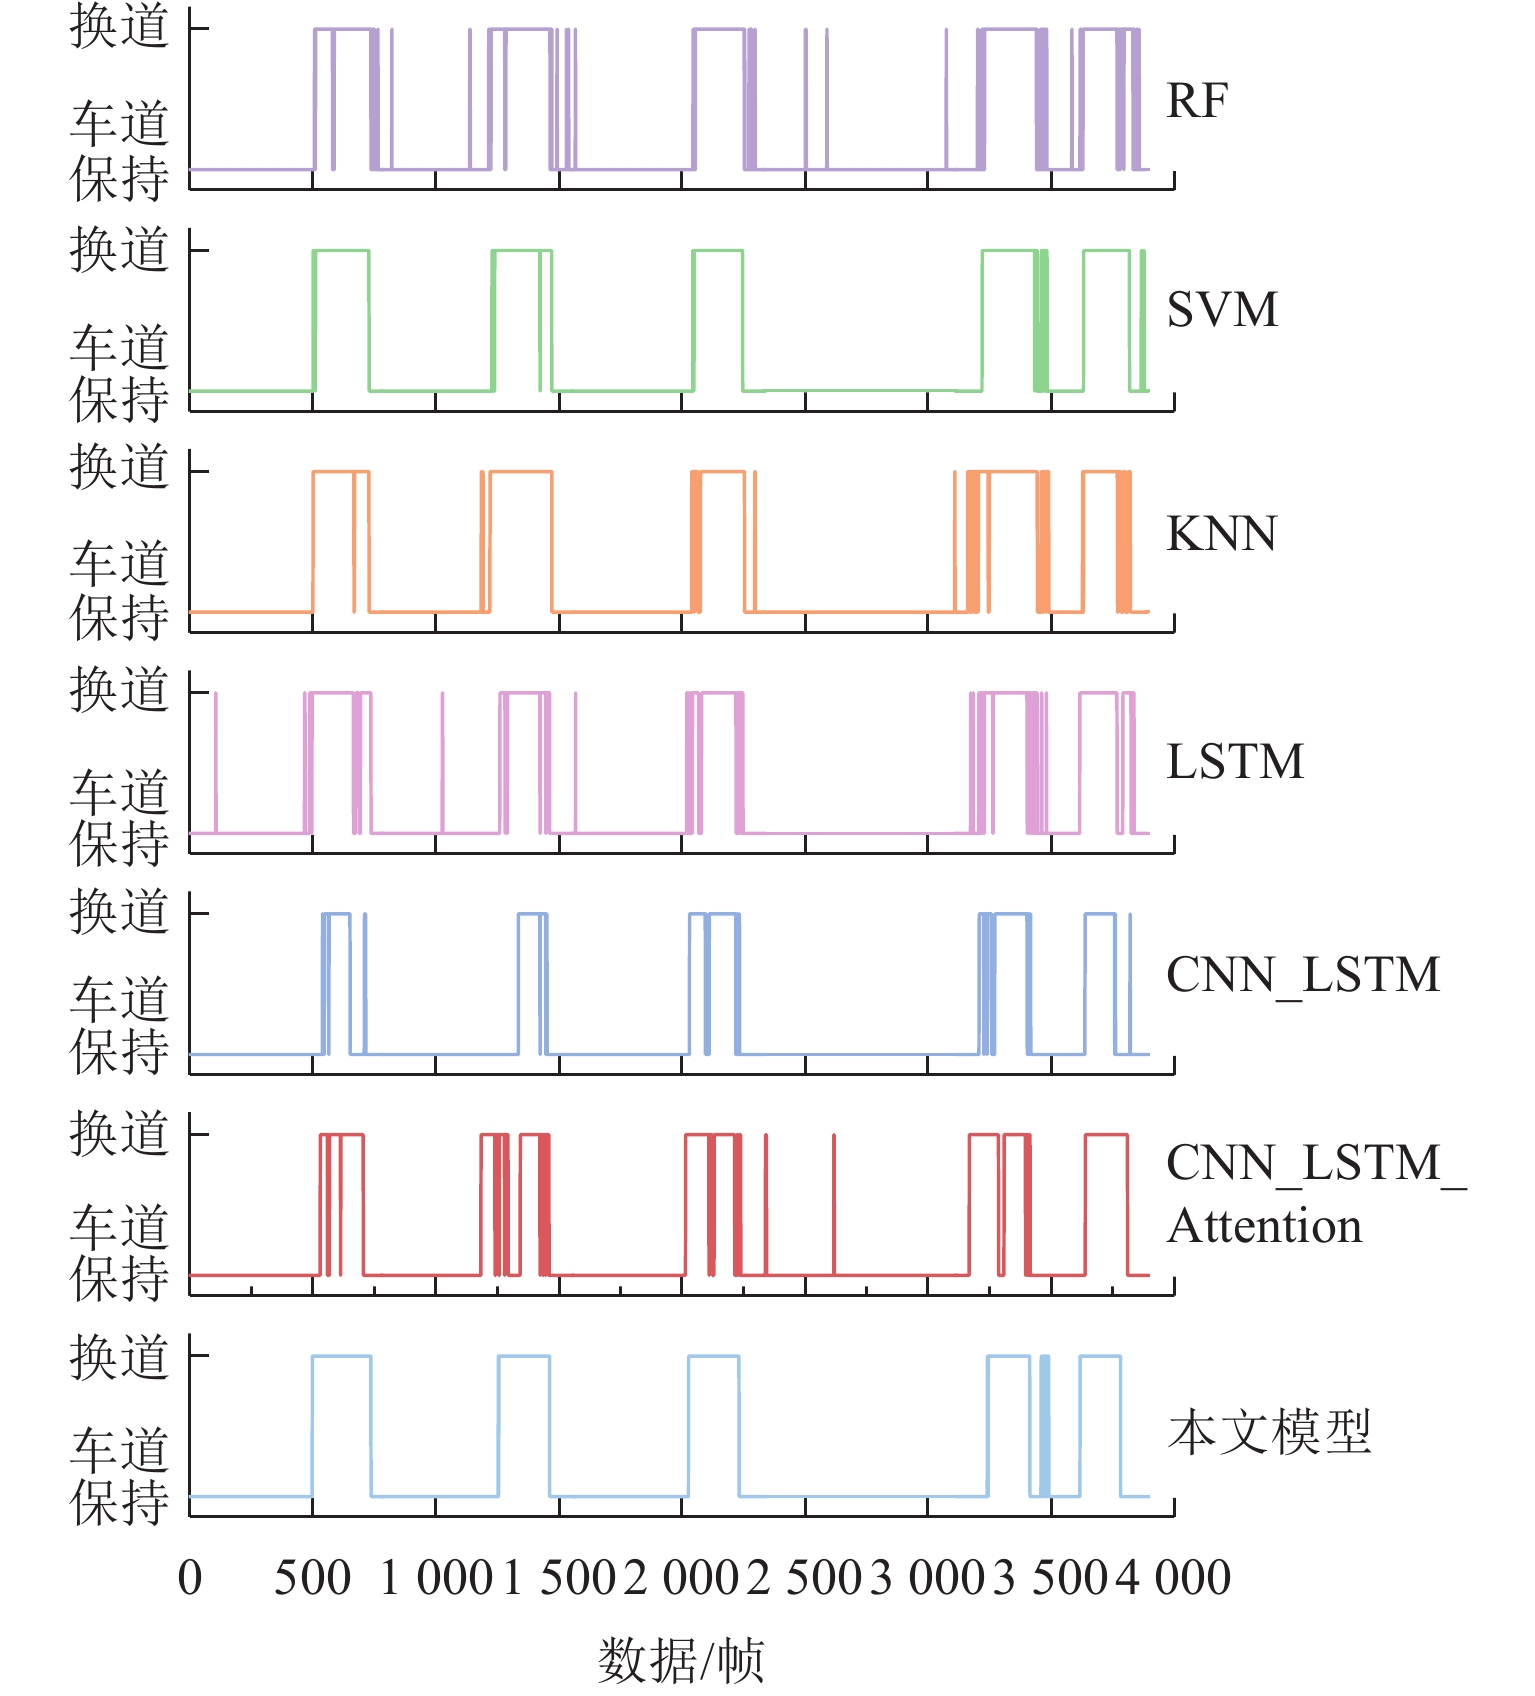
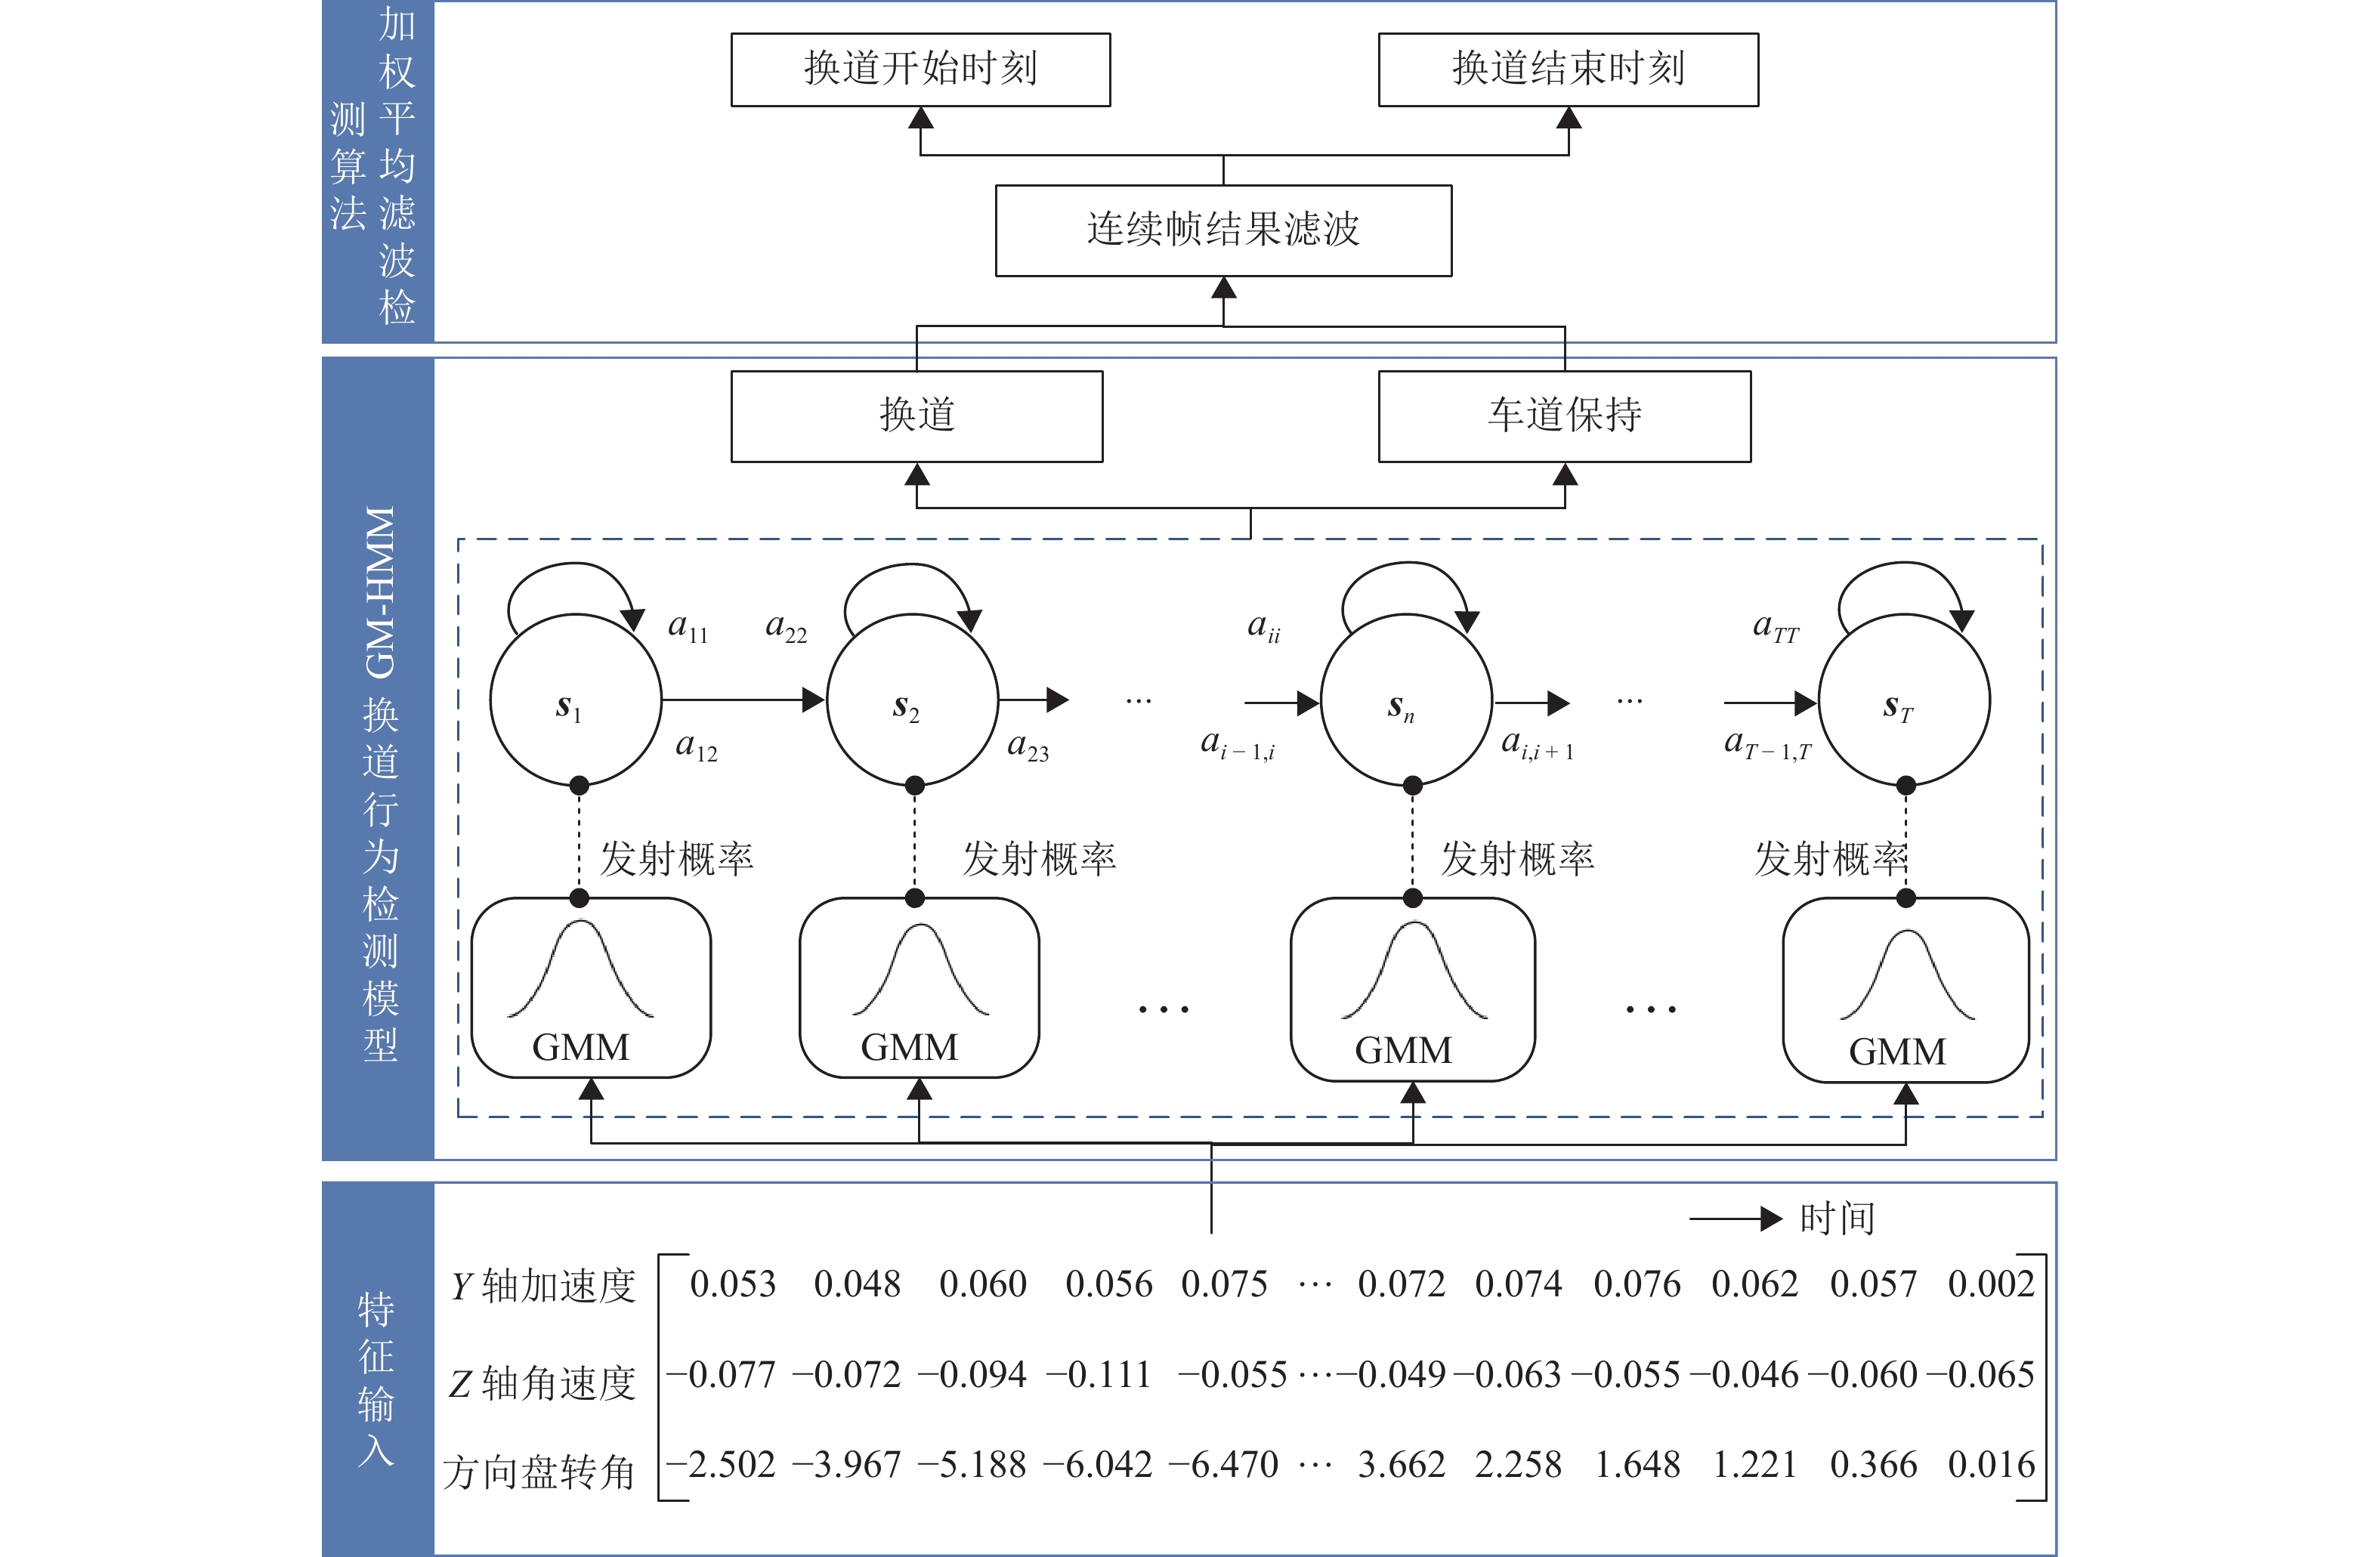
Improper lane-changing behavior is a significant contributing factor to traffic accidents. The accurate detection of lane-changing maneuvers is a crucial element in the enhancement of vehicle safety. Few studies have examined the entire lane-changing process, limiting the ability to capture dynamic variations throughout the maneuver and resulting in detection outcomes that fail to meet practical application demands. To address this limitation, an integrated lane-change detection method that combines Global Navigation Satellite System (GNSS), vehicle attitude, and controller area network (CAN) bus time-series data is proposed to determine whether a lane change occurs and identify its start and end times. To improve real-time detection performance, a lane-changing behavior detection framework based on a multidimensional Gaussian mixture hidden Markov model (GM-HMM) was developed. A total of 600 samples were collected for model training and comparison. Lateral acceleration, angular velocity, and steering wheel angle data were used as model inputs, and a real-vehicle testing platform was built for data collection and model validation. The results demonstrate that the proposed model achieves a high detection accuracy of 96.67% under a single operating condition. Moreover, under combined operating conditions, the proposed model outperforms other algorithms, including support vector machines (SVMs) and long short-term memory (LSTM) networks, in terms of real-time detection performance, stability, and resistance to interference, demonstrating its advantages in key aspects of lane-change detection.

| [1] |
Li G F, Li S E, Cheng B, et al. Estimation of driving style in naturalistic highway traffic using maneuver transition probabilities[J]. Transportation Research Part C: Emerging Technologies, 2017, 74: 113-125. doi: 10.1016/j.trc.2016.11.011
|
| [2] |
Habenicht S, Winner H, Bone S, et al. A maneuver-based lane change assistance system[C]//2011 IEEE Intelligent Vehicles Symposium (IV). Baden-Baden, Germany. IEEE, 2011: 375-380.
|
| [3] |
Tran D, Du J H, Sheng W H, et al. A human-vehicle collaborative driving framework for driver assistance[J]. IEEE Transactions on Intelligent Transportation Systems, 2019, 20(9): 3470-3485. doi: 10.1109/TITS.2018.2878027
|
| [4] |
Xie D F, Fang Z Z, Jia B, et al. A data-driven lane-changing model based on deep learning[J]. Transportation Research Part C: Emerging Technologies, 2019, 106: 41-60. doi: 10.1016/j.trc.2019.07.002
|
| [5] |
Singh H, Kathuria A. Analyzing driver behavior under naturalistic driving conditions: a review[J]. Accident Analysis & Prevention, 2021, 150: 105908. doi: 10.1016/j.aap.2020.105908
|
| [6] |
Toledo T, Musicant O, Lotan T. In-vehicle data recorders for monitoring and feedback on drivers’ behavior[J]. Transportation Research Part C: Emerging Technologies, 2008, 16(3): 320-331. doi: 10.1016/j.trc.2008.01.001
|
| [7] |
Bi H K, Bi H K, Mao T L, et al. A data-driven model for lane-changing in traffic simulation[C]//Proceedings of the ACM SIGGRAPH/Eurographics Symposium on Computer Animation. ACM, 2016: 149-158.
|
| [8] |
Shi H L, Wang T L, Zhong F S, et al. A data-driven car-following model based on the random forest[J]. World Journal of Engineering and Technology, 2021, 9(3): 503-515. doi: 10.4236/wjet.2021.93033
|
| [9] |
Teimouri F, Ghatee M. A real-time warning system for rear-end collision based on random forest classifier[J]. Journal of Soft Computing in Civil Engineering, 2020, 4(1): 49-71.
|
| [10] |
Sun Q Y, Wang C, Fu R, et al. Lane change strategy analysis and recognition for intelligent driving systems based on random forest[J]. Expert Systems with Applications, 2021, 186: 115781. doi: 10.1016/j.eswa.2021.115781
|
| [11] |
Hallac D, Sharang A, Stahlmann R, et al. Driver identification using automobile sensor data from a single turn[C]//2016 IEEE 19th International Conference on Intelligent Transportation Systems (ITSC). Piscataway: IEEE, 2016: 953-958.
|
| [12] |
徐婷, 邓恺龙, 刘永涛, 等. 基于航测数据的不同风格换道轨迹规划[J]. 西南交通大学学报, 2024, 59(3): 720-728. doi: 10.3969/j.issn.0258-2724.20230392
Xu Ting, Deng Kailong, Liu Yongtao, et al. Different styles of lane changing trajectory planning based on aerial survey data[J]. Journal of Southwest Jiaotong University, 2024, 59(3): 720-728. doi: 10.3969/j.issn.0258-2724.20230392
|
| [13] |
Wu X R, Zhou J W, An J H, et al. Abnormal driving behavior detection for bus based on the Bayesian classifier[C]//2018 Tenth International Conference on Advanced Computational Intelligence (ICACI). Xiamen, China. IEEE, 2018: 266-272.
|
| [14] |
苏丽娜, 李凡, 潘秀, 等. 基于雷达数据的车辆换道行为识别研究[J]. 北京交通大学学报, 2022, 46(4): 60-67. doi: 10.11860/j.issn.1673-0291.20210136
Su Lina, Li Fan, Pan Xiu, et al. Detection of vehicle lane-changing behavior based on radar data[J]. Journal of Beijing Jiaotong University, 2022, 46(4): 60-67. doi: 10.11860/j.issn.1673-0291.20210136
|
| [15] |
Zheng Y, Hansen J H L. Lane-change detection from steering signal using spectral segmentation and learning-based classification[J]. IEEE Transactions on Intelligent Vehicles, 2017, 2(1): 14-24. doi: 10.1109/TIV.2017.2708600
|
| [16] |
Sharma O, Sahoo N C, Puhan N B. Highway discretionary lane changing behavior recognition using continuous and discrete hidden Markov model[C]//2021 IEEE International Intelligent Transportation Systems Conference (ITSC). Piscataway: IEEE, 2021: 1476-1481.
|
| [17] |
Jin H, Duan C G, Liu Y, et al. Gauss mixture hidden Markov model to characterise and model discretionary lane-change behaviours for autonomous vehicles[J]. IET Intelligent Transport Systems, 2020, 14(5): 401-411. doi: 10.1049/iet-its.2019.0446
|
| [18] |
徐婷, 温常磊, 张香, 等. 基于GMM-CHMM的城市道路换道行为识别[J]. 交通运输系统工程与信息, 2020, 20(1): 61-67. doi: 10.16097/j.cnki.1009-6744.2020.01.010
Xu Ting, Wen Changlei, Zhang Xiang, et al. Lane changing behavior identification of urban road based on GMM-CHMM[J]. Journal of Transportation Systems Engineering and Information Technology, 2020, 20(1): 61-67. doi: 10.16097/j.cnki.1009-6744.2020.01.010
|
| [19] |
Chen S Y, Yao H, Qiao F X, et al. Vehicles driving behavior recognition based on transfer learning[J]. Expert Systems with Applications, 2023, 213: 119254. doi: 10.1016/j.eswa.2022.119254
|
| [20] |
赵建东, 赵志敏, 屈云超, 等. 轨迹数据驱动的车辆换道意图识别研究[J]. 交通运输系统工程与信息, 2022, 22(4): 63-71. doi: 10.16097/j.cnki.1009-6744.2022.04.007
Zhao Jiandong, Zhao Zhimin, Qu Yunchao, et al. Vehicle lane change intention recognition driven by trajectory data[J]. Journal of Transportation Systems Engineering and Information Technology, 2022, 22(4): 63-71. doi: 10.16097/j.cnki.1009-6744.2022.04.007
|
| [21] |
王婉琦, 程国柱, 徐亮. 基于无监督聚类分析的激进换道行为识别方法[J]. 交通运输系统工程与信息, 2024, 24(2): 166-178. doi: 10.16097/j.cnki.1009-6744.2024.02.017
Wang Wanqi, Cheng Guozhu, Xu Liang. Identification of aggressive lane-changing behaviour based on unsupervised cluster analysis[J]. Journal of Transportation Systems Engineering and Information Technology, 2024, 24(2): 166-178. doi: 10.16097/j.cnki.1009-6744.2024.02.017
|
| [22] |
Hu X H, Chen S Z, Zhao J H, et al. Risk identification and prediction model for continuous‐lane‐change vehicles considering driving style[J]. Expert Systems with Applications, 2025, 259: 125292. doi: 10.1016/j.eswa.2024.125292
|
| [23] |
Liao X S, Zhao X P, Wang Z R, et al. Driver digital twin for online prediction of personalized lane-change behavior[J]. IEEE Internet of Things Journal, 2023, 10(15): 13235-13246. doi: 10.1109/JIOT.2023.3262484
|
| [24] |
Knoop V L, De Bakker P F, Tiberius C C J M, et al. Lane determination with GPS precise point positioning[J]. IEEE Transactions on Intelligent Transportation Systems, 2017, 18(9): 2503-2513. doi: 10.1109/TITS.2016.2632751
|
| [25] |
Tang L L, Yang X, Kan Z H, et al. Lane-level road information mining from vehicle GPS trajectories based on Naïve Bayesian classification[J]. ISPRS International Journal of Geo-Information, 2015, 4(4): 2660-2680. doi: 10.3390/ijgi4042660
|
| [26] |
Yuan Y, Li Y B, Bao H P. An empirical study on the lane-change duration of naturalistic driving based on multiple linear regression model[C]//2020 IEEE International Conference on Artificial Intelligence and Information Systems (ICAIIS). Dalian, China. IEEE, 2020: 381-387.
|
Figures(10) / Tables(6)

 DownLoad: